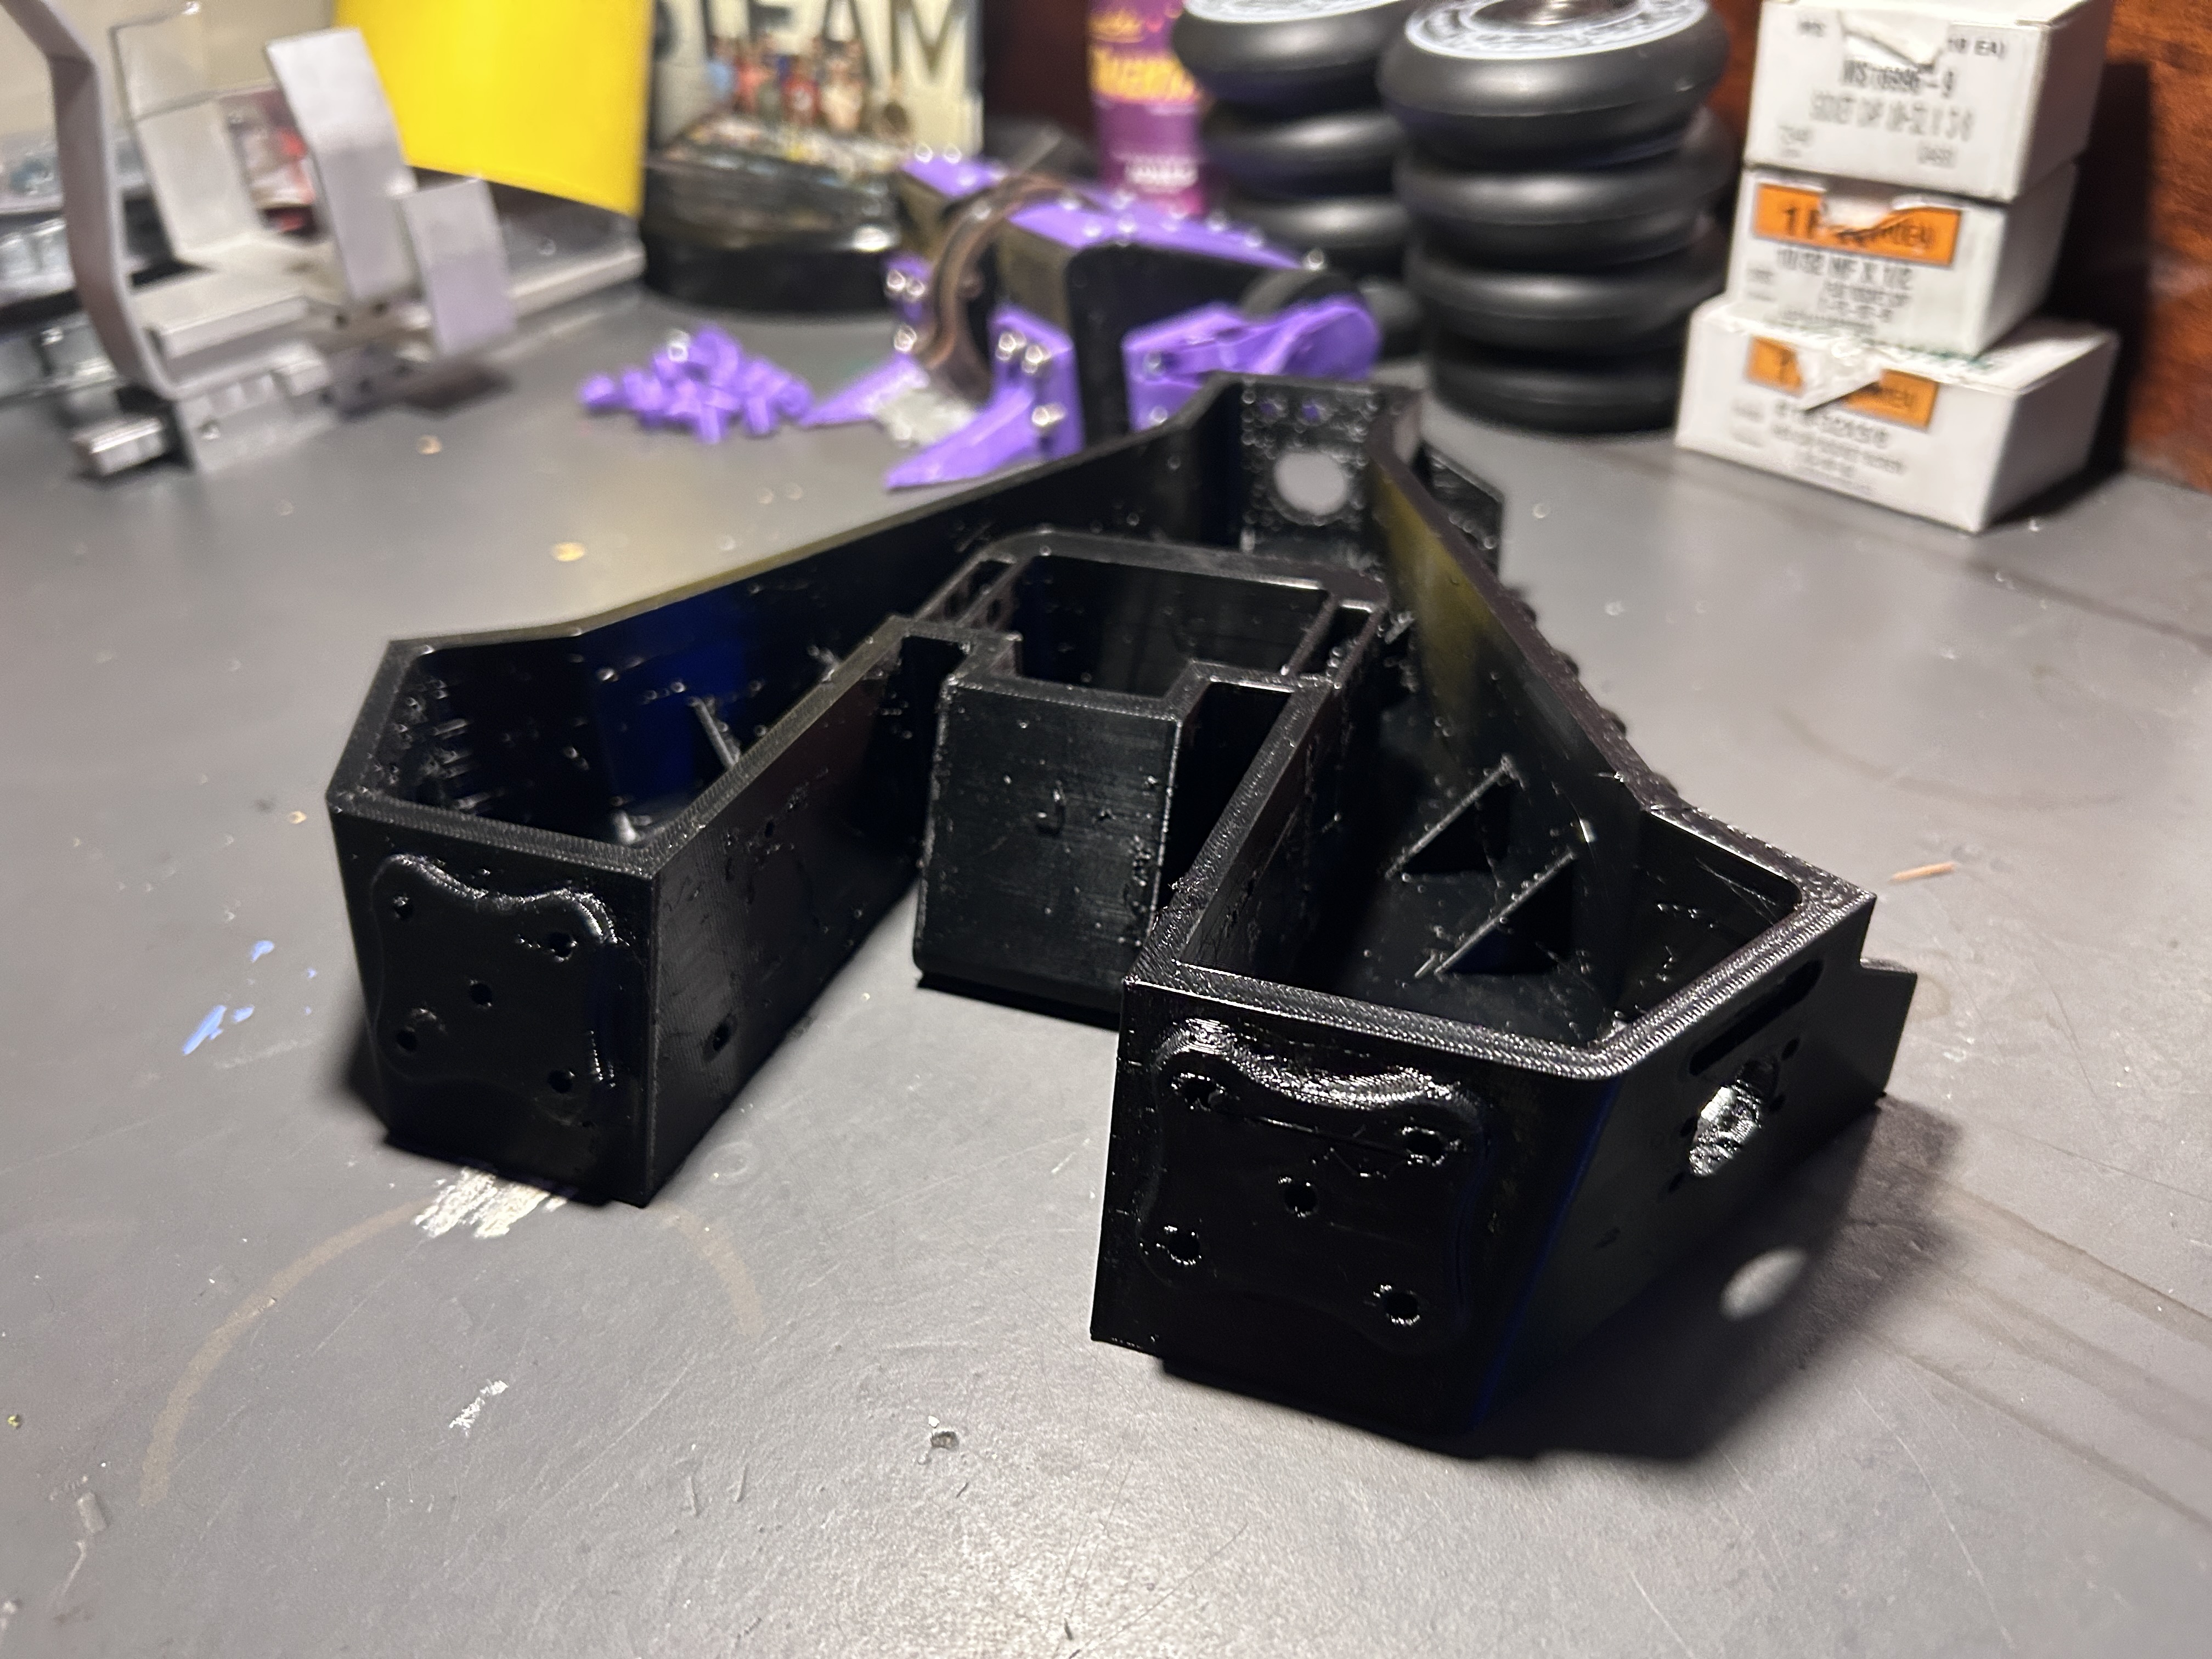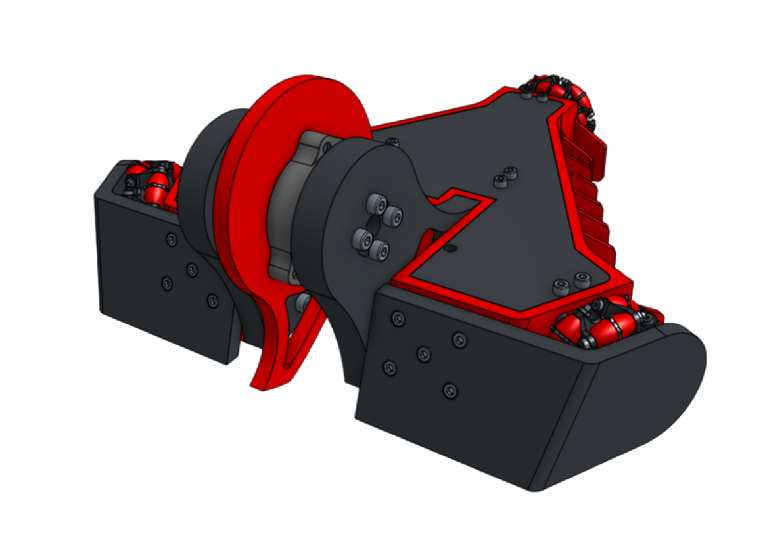
About Lobstah
Lobstah is a 3 lb beetleweight combat robot I’m currently designing. Like many combat robots, it uses a large vertical spinner as its primary weapon. The unusual part is its triangular arrangement of omniwheels, which is designed to let the robot rotate and move in any direction at the same time.
The design is complete, but Lobstah has not been battle tested yet. I’m excited to see whether the wheel design works in an arena and whether the idea could be useful in other weight classes.
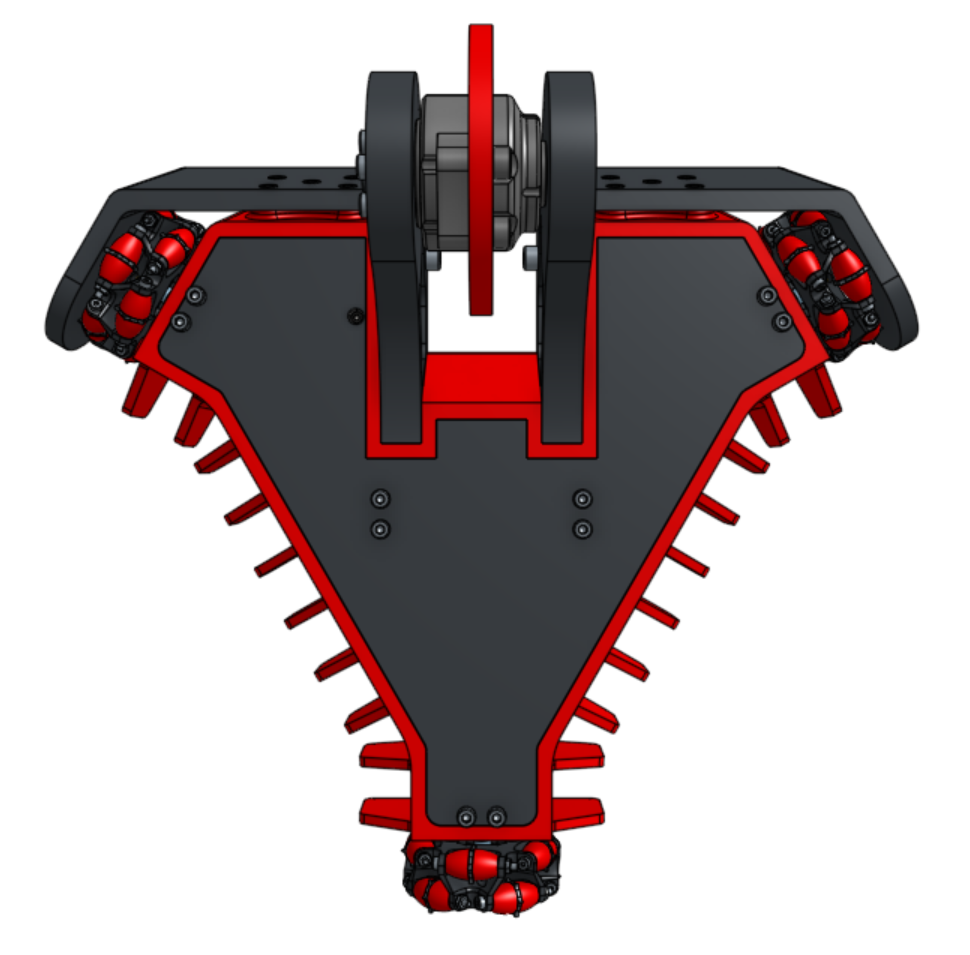
Cleated wheels for arena traction
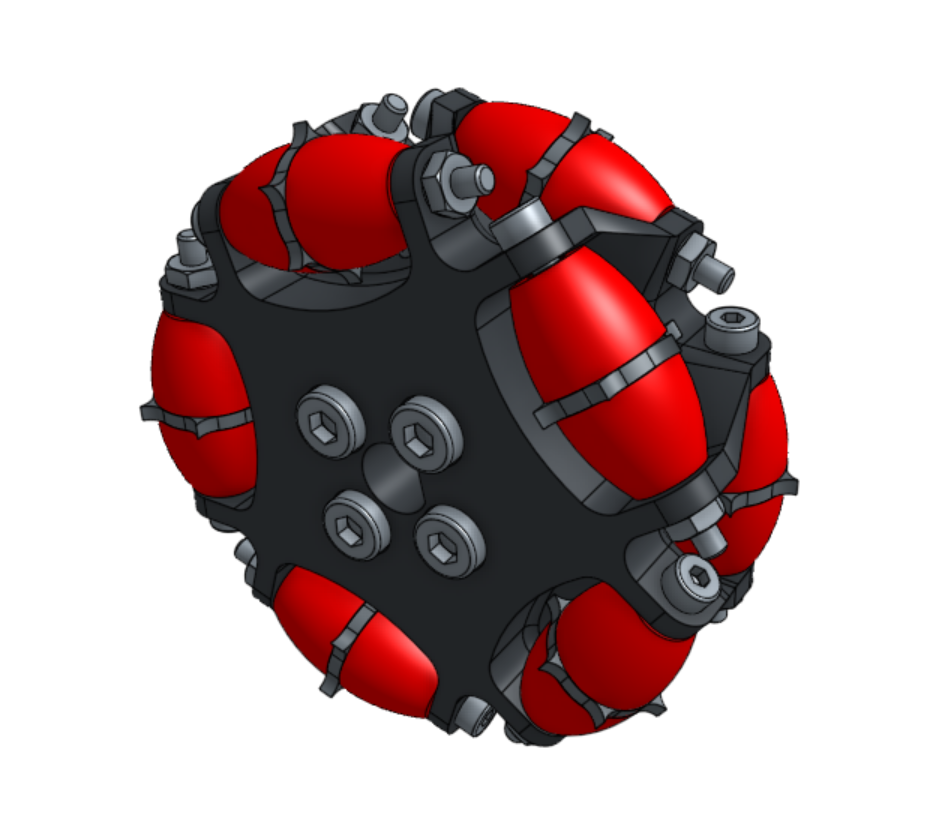
I designed and 3D printed the omniwheels in TPU to help absorb impacts. I added metal cleats to the rollers inside each wheel to improve traction on the wooden floors used in many combat robotics arenas.
The vertical spinner also creates a gyroscopic precession challenge that I’ll need to account for. I’m interested to see whether strafing sideways will make the robot easier to control than turning in the usual way while the weapon is spinning.
Design & Build
Additional CAD and fabrication views.