01 / PROJECT OVERVIEW
A compact attachment for a scaled excavator
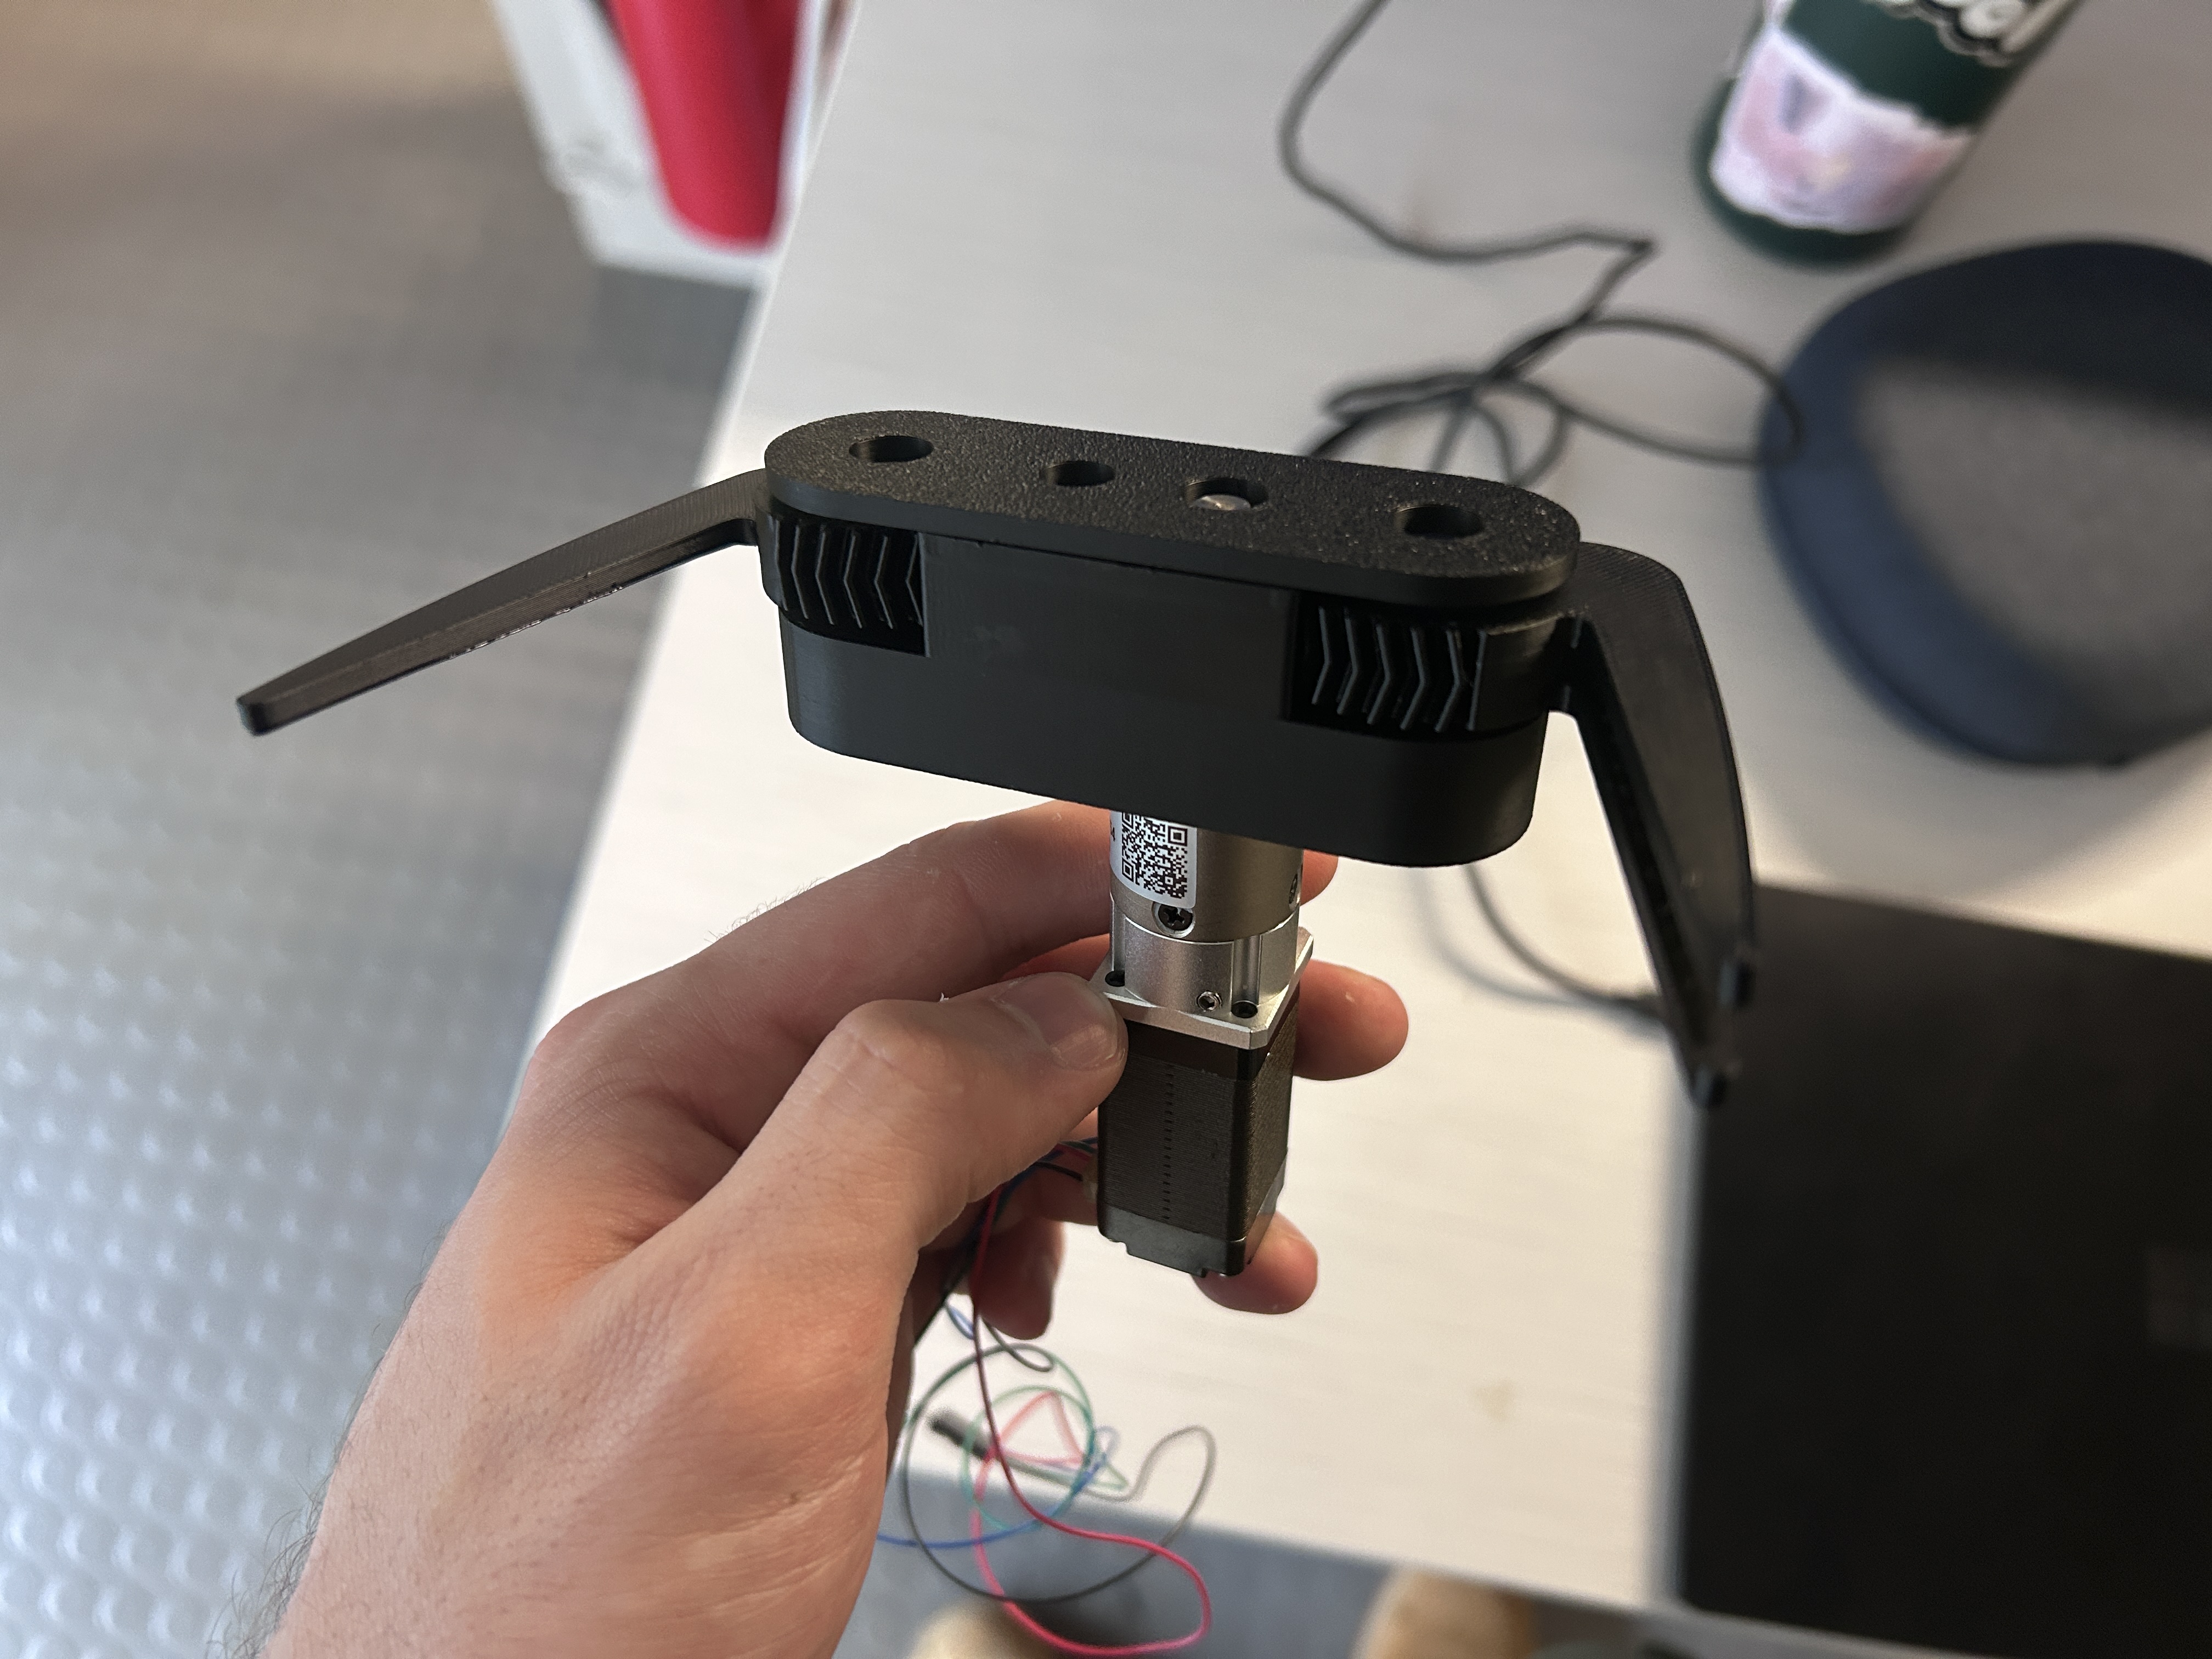
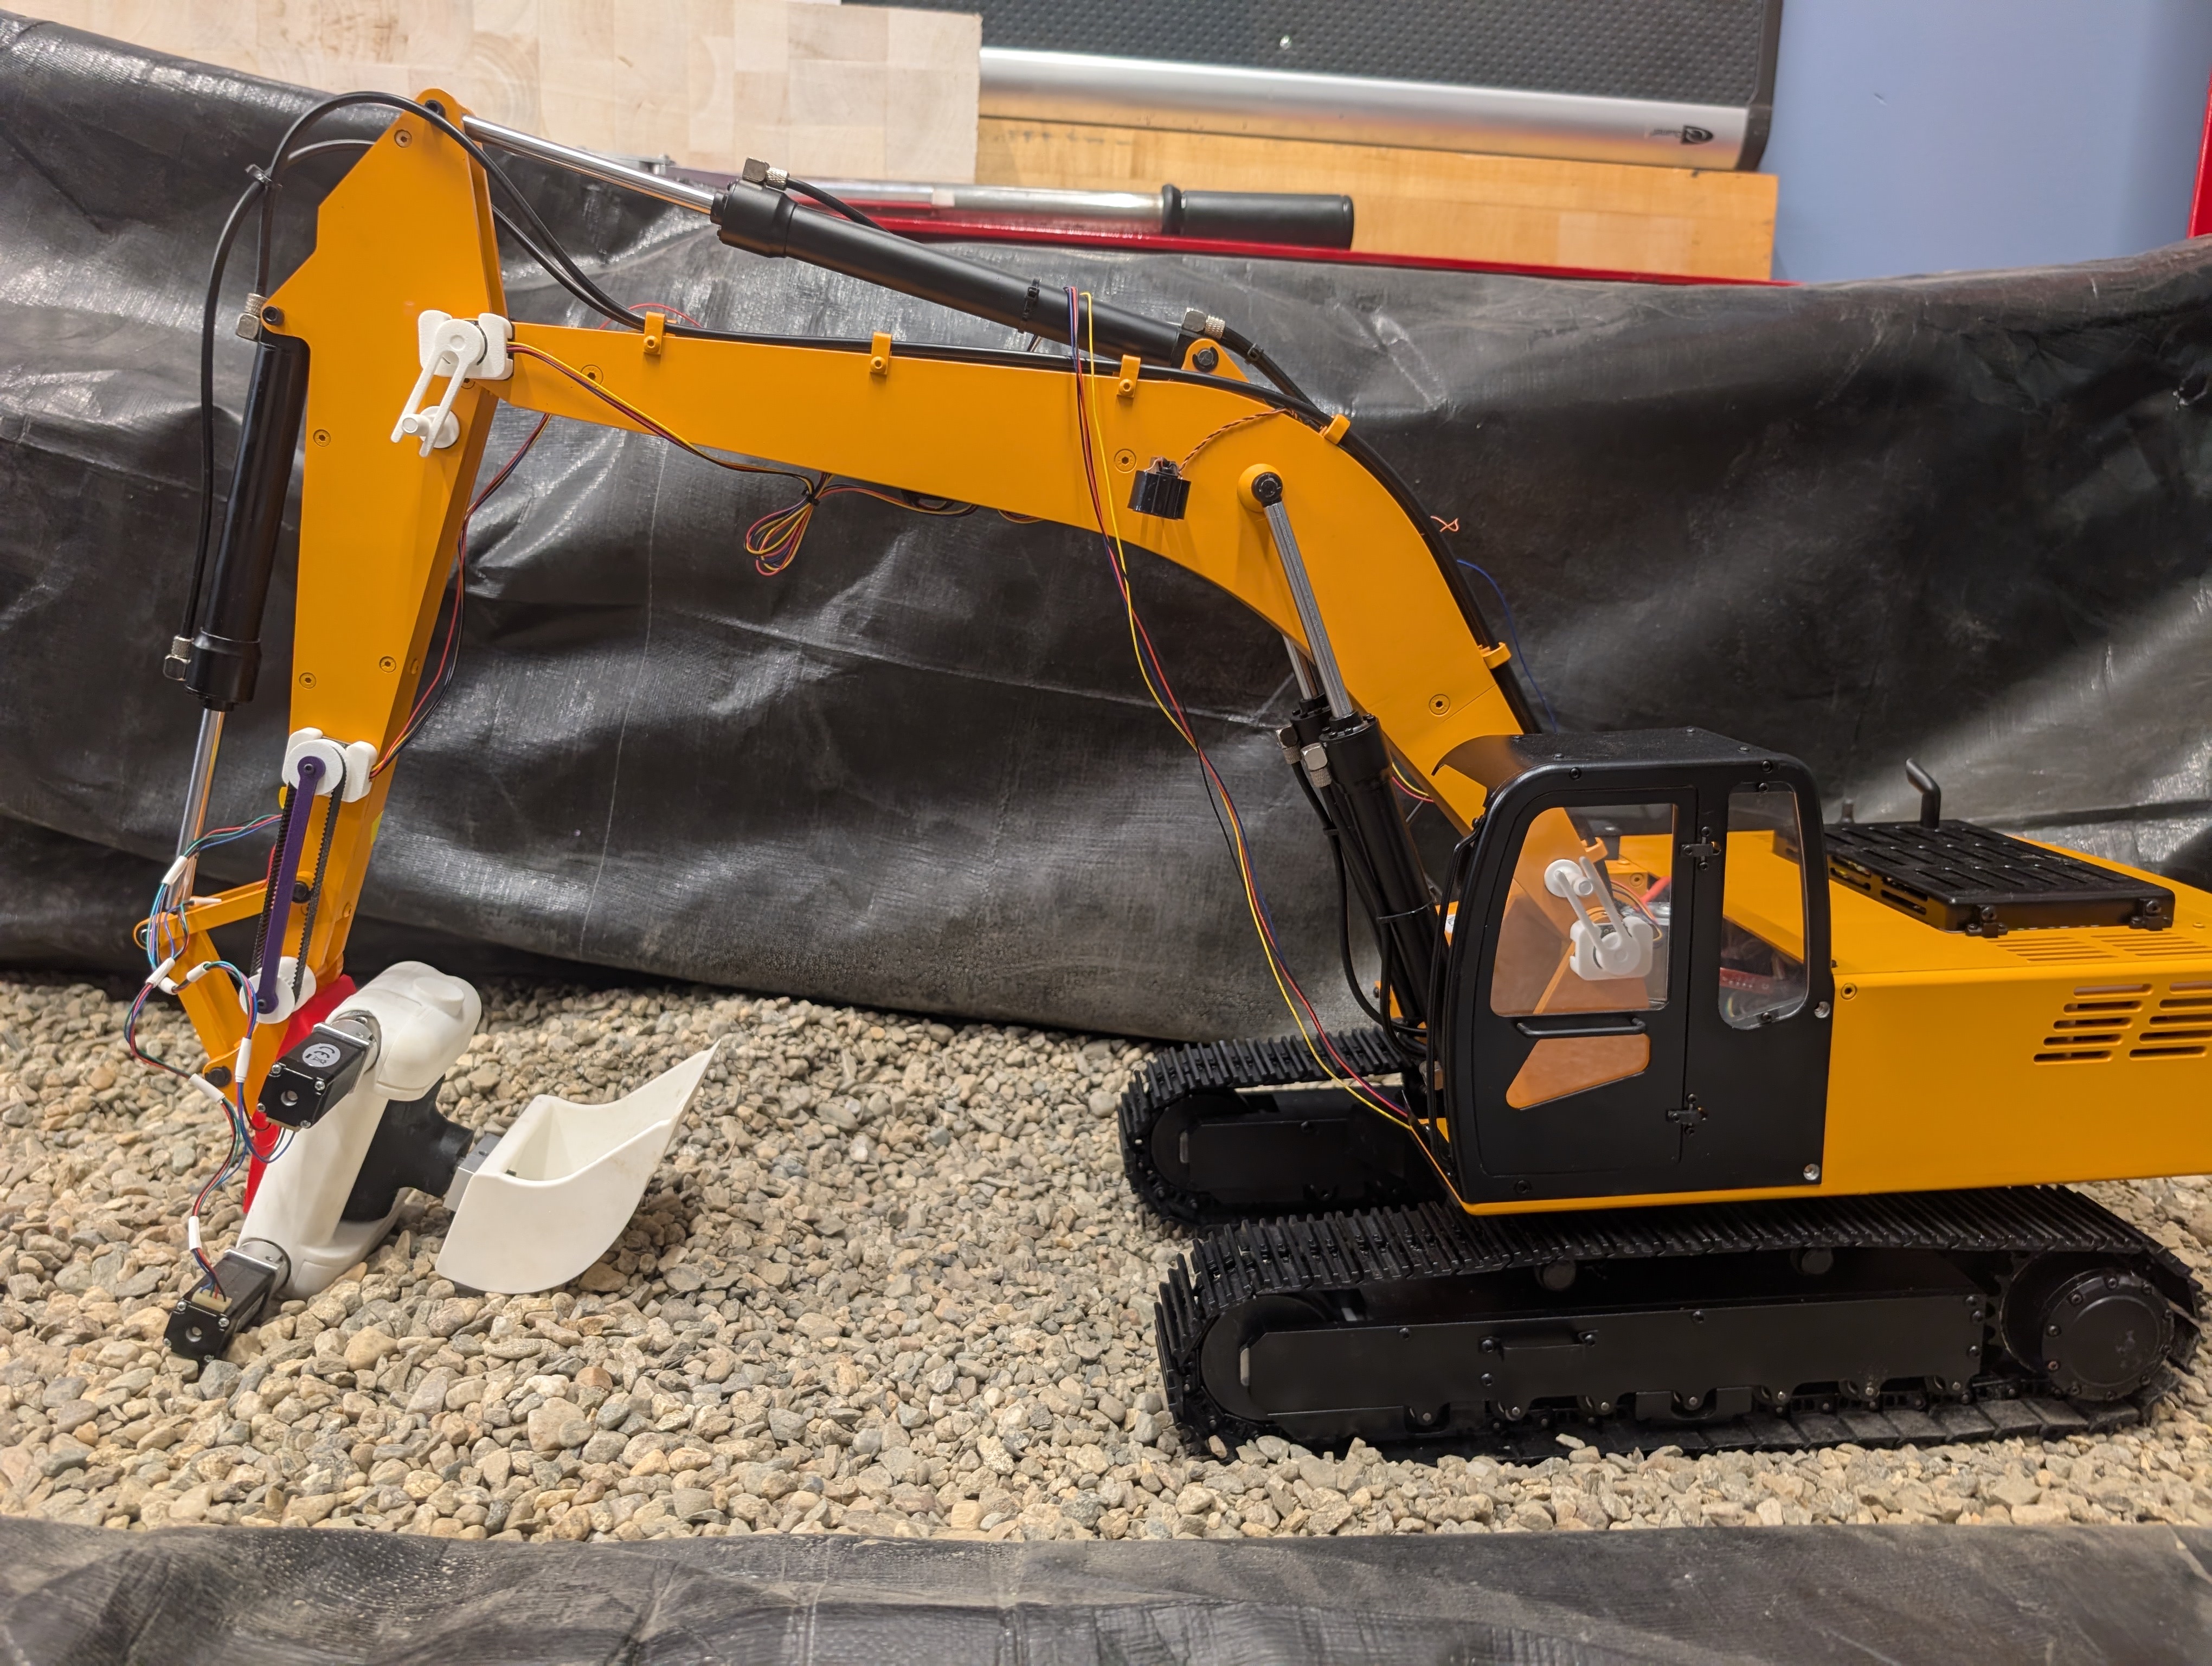
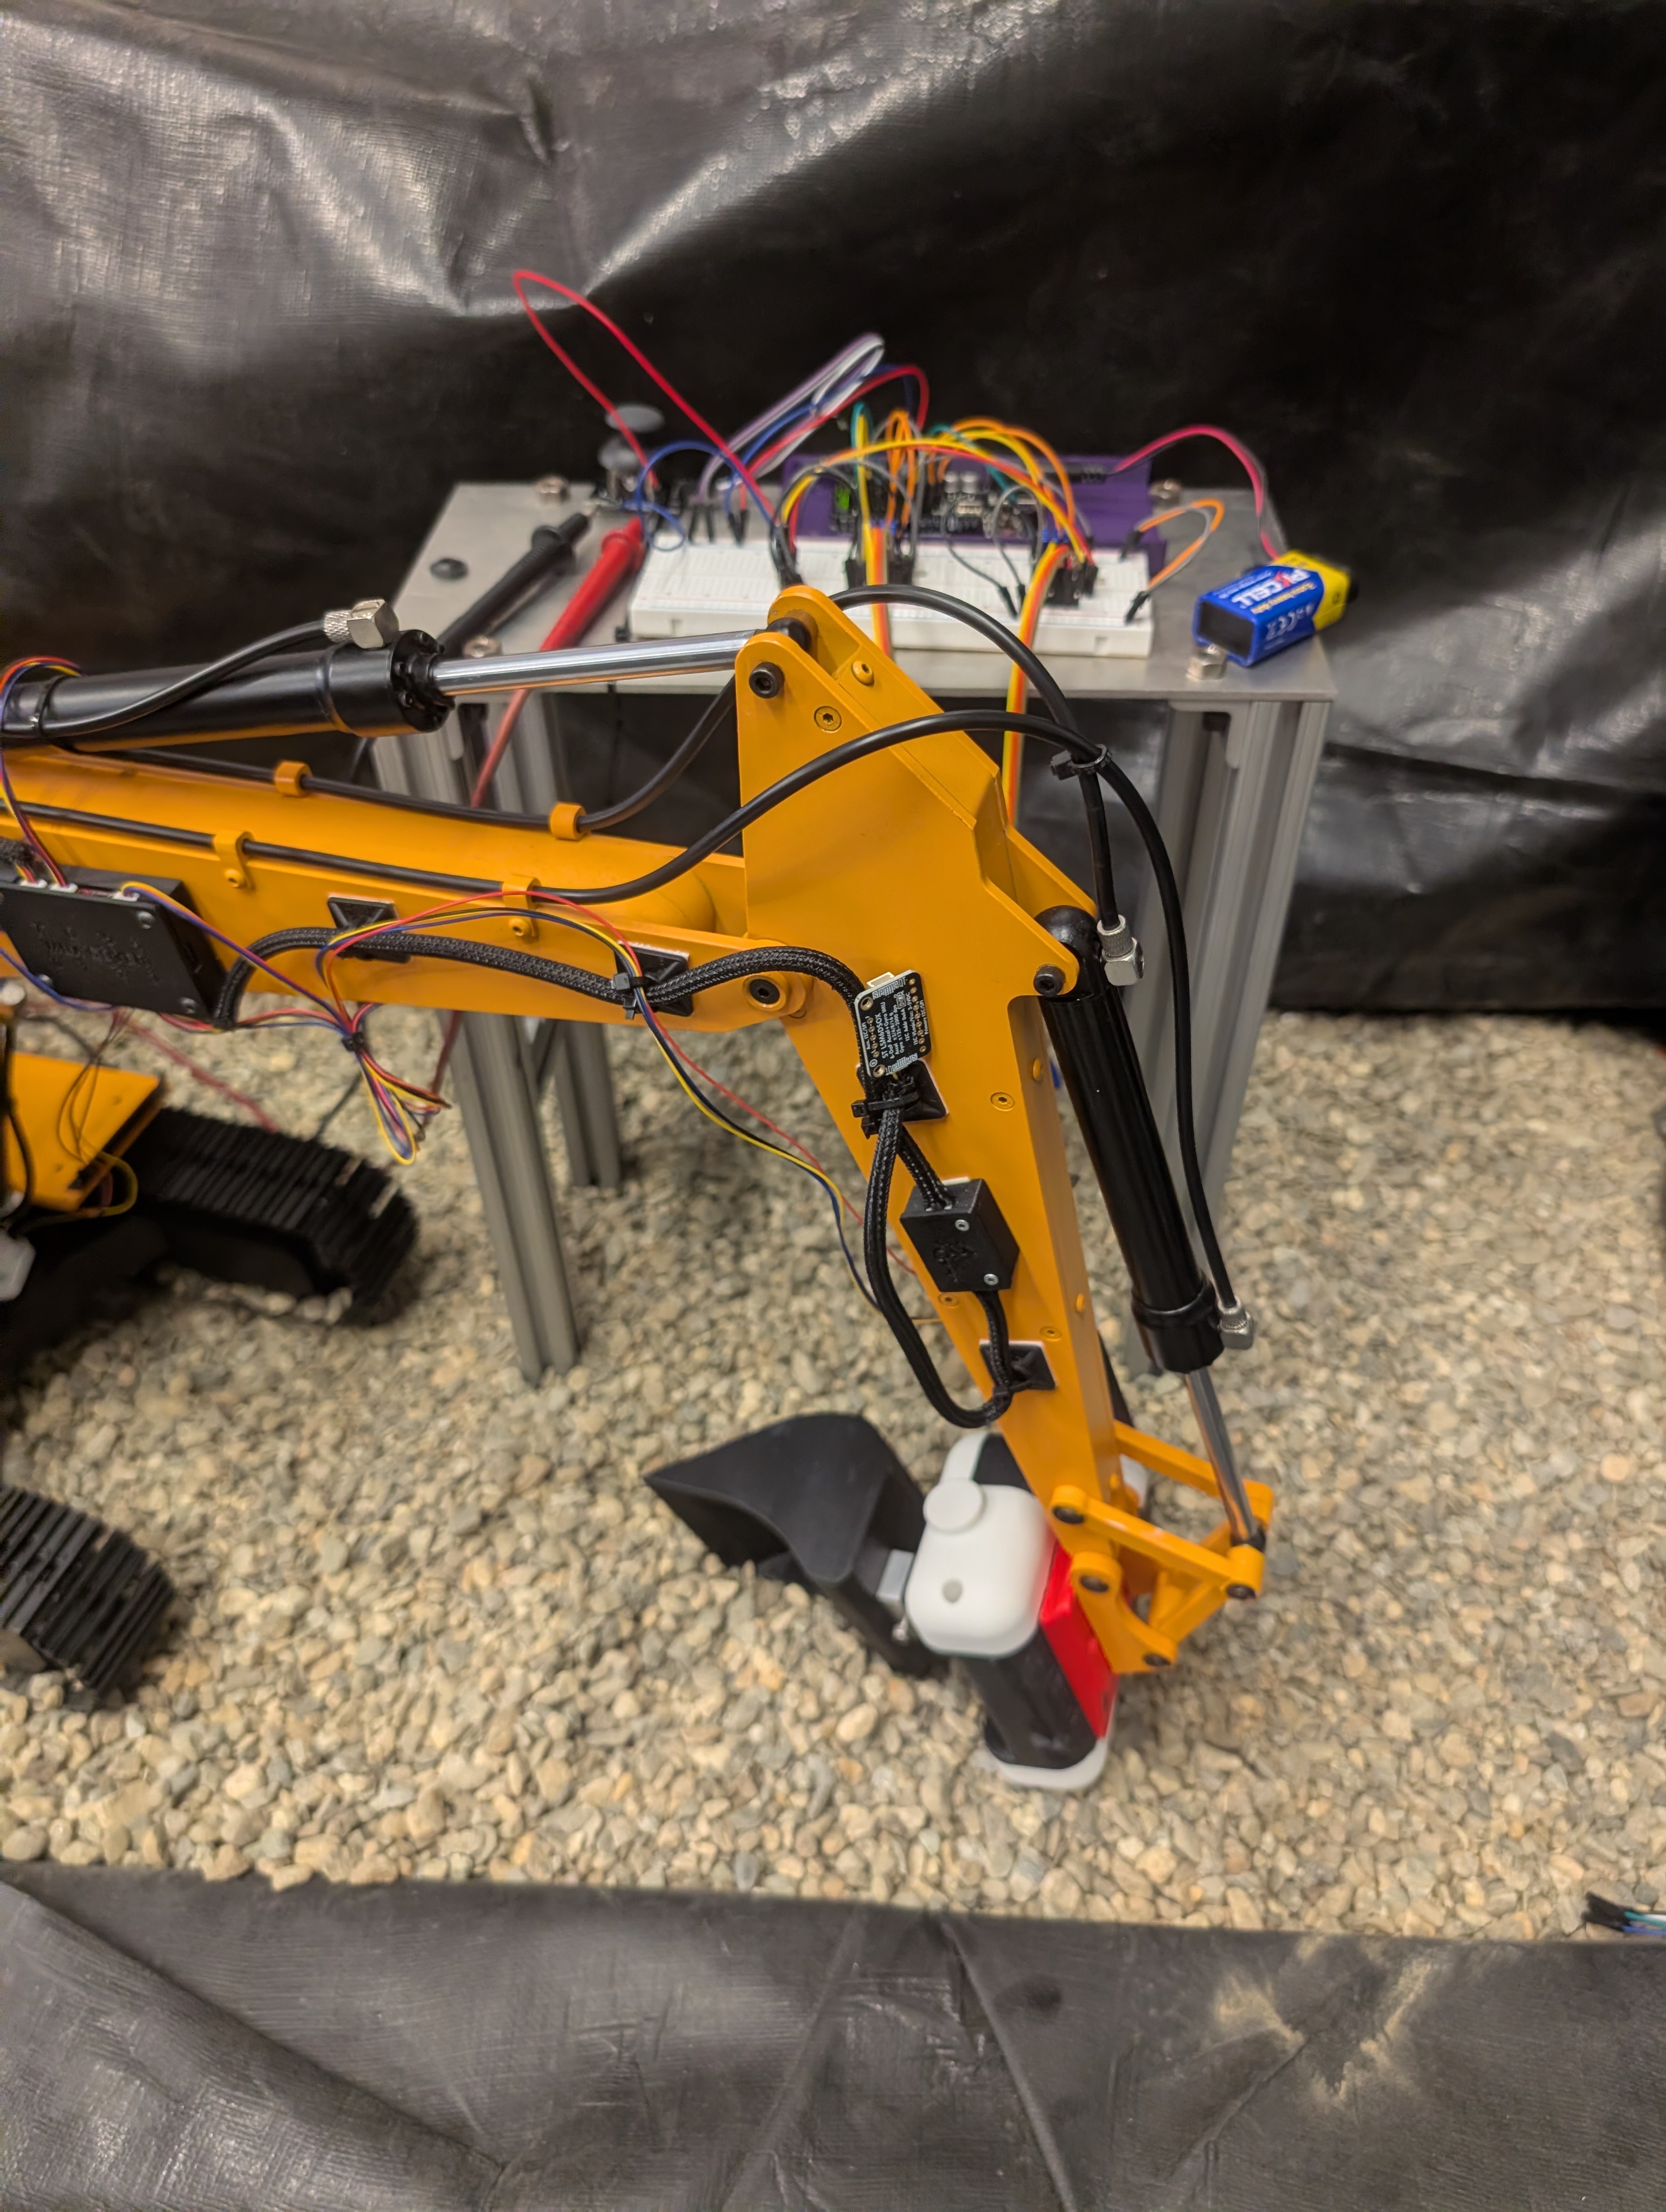
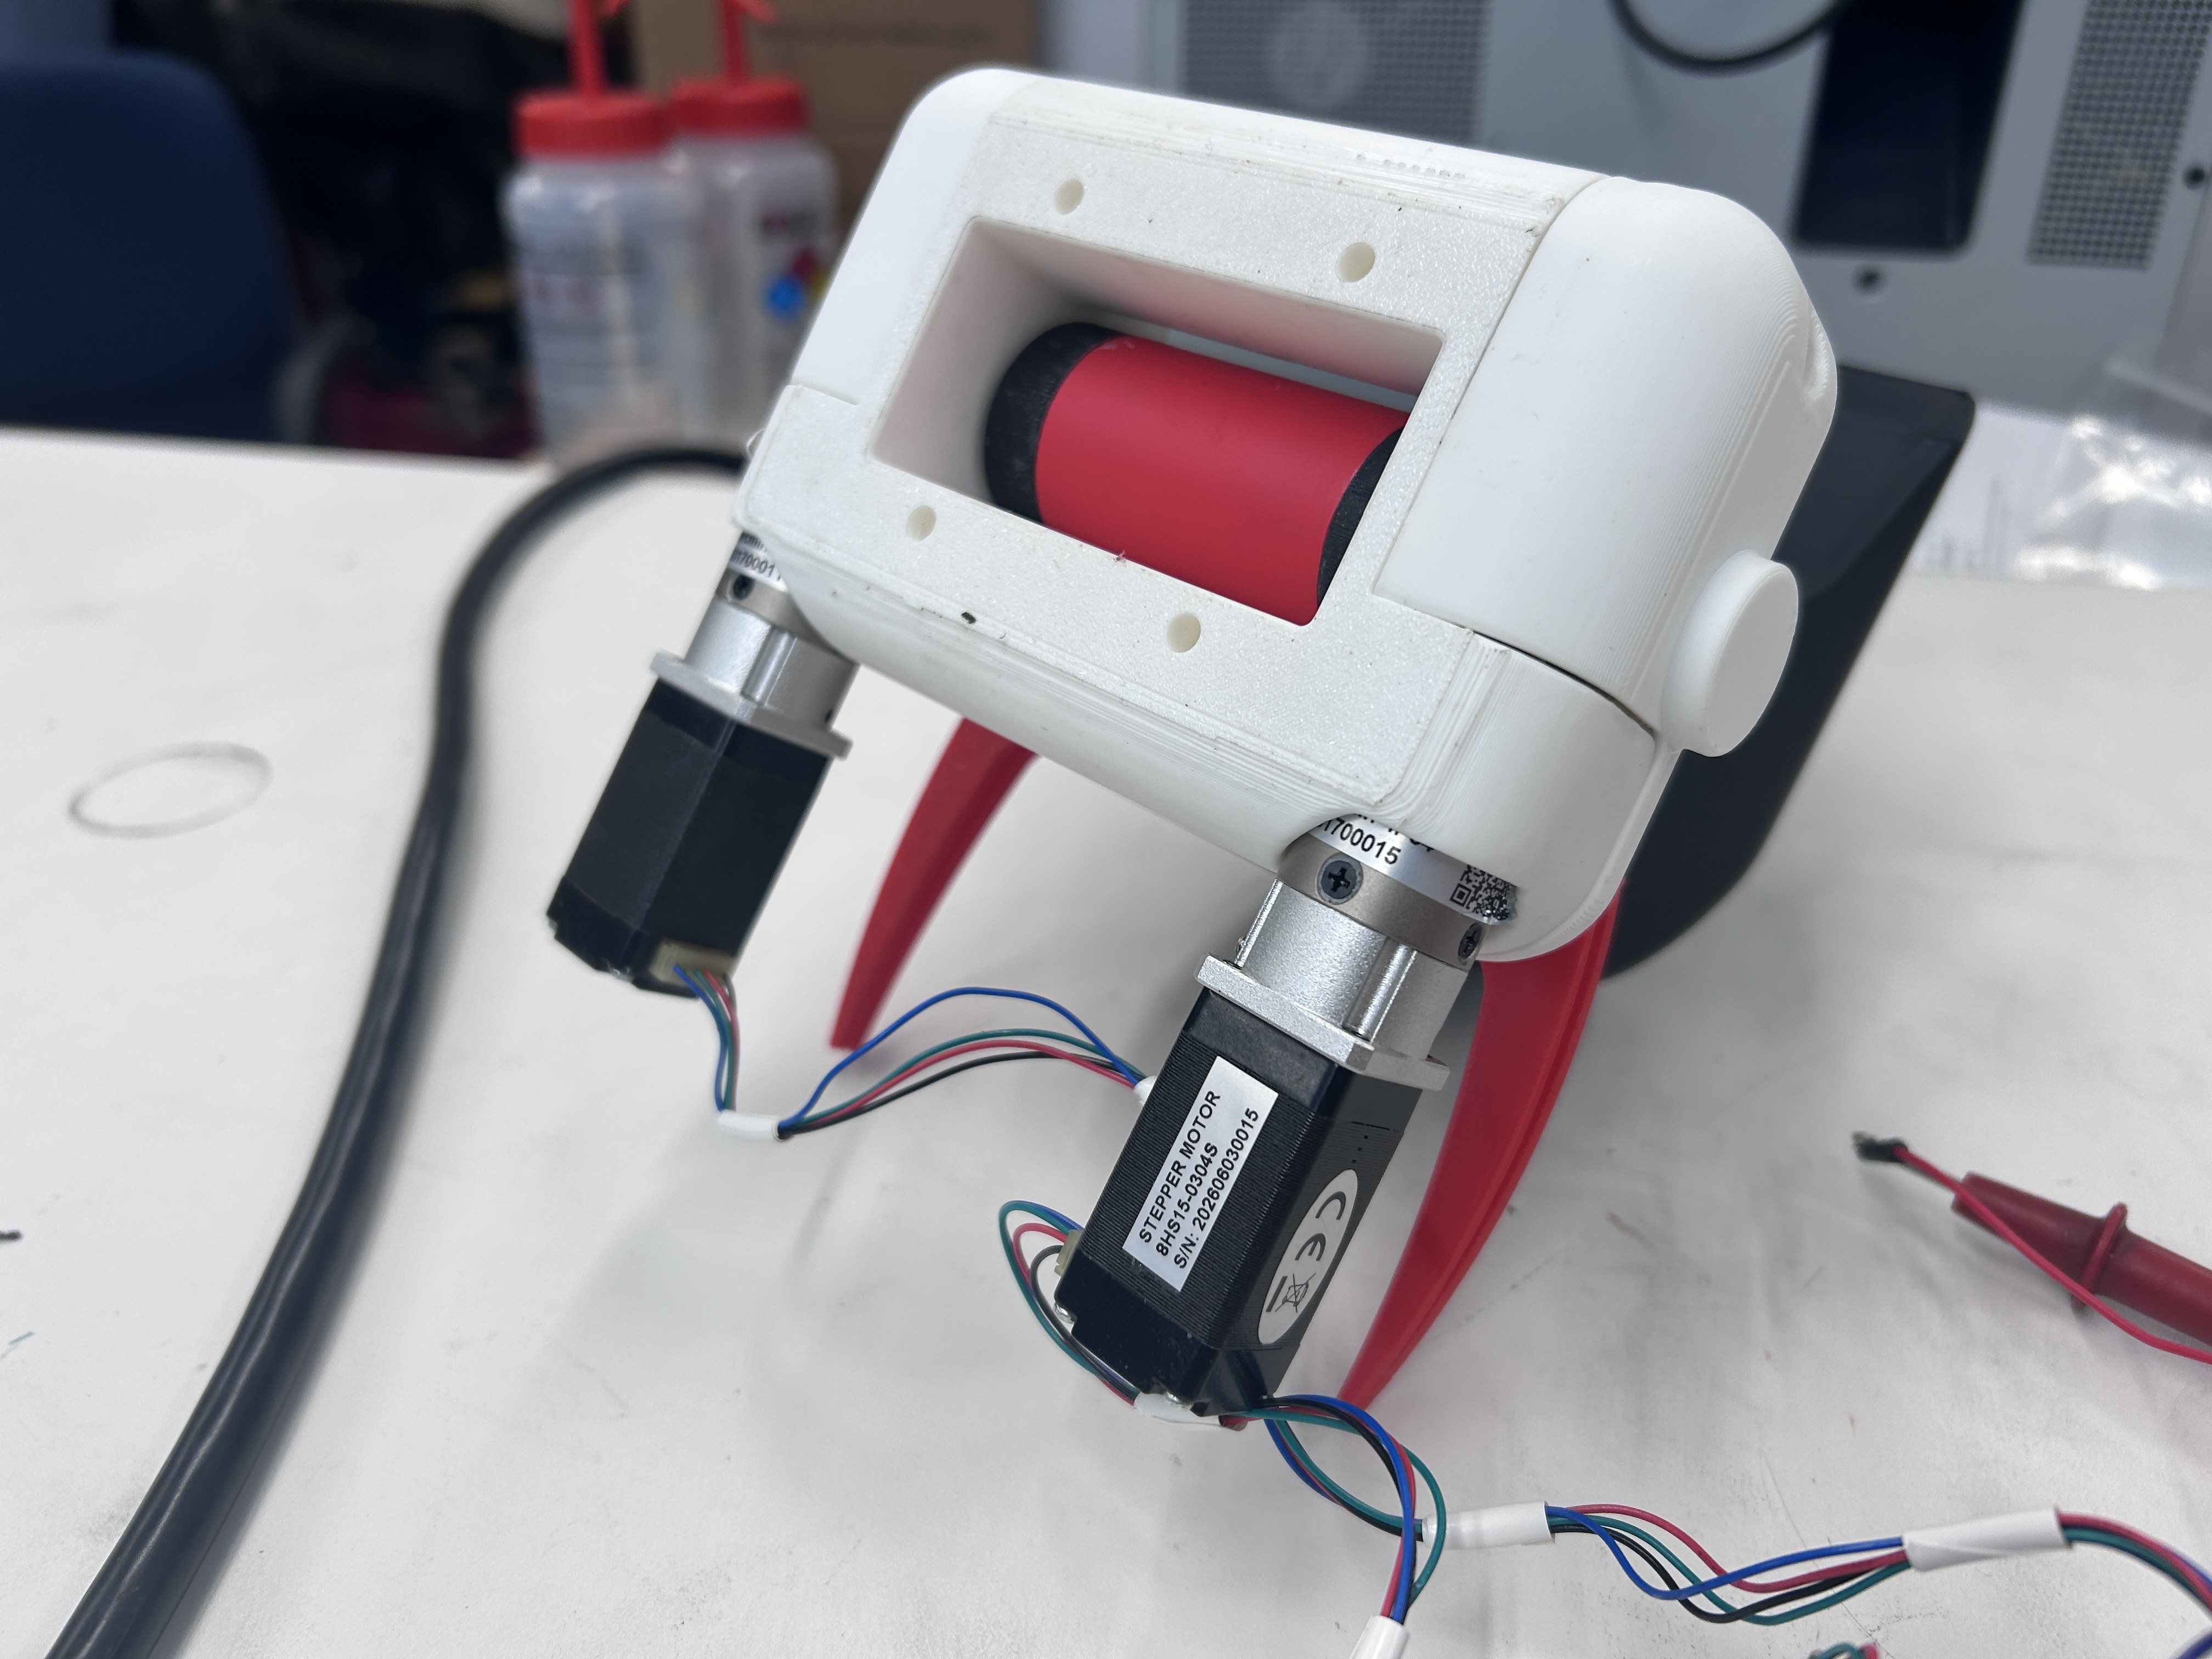
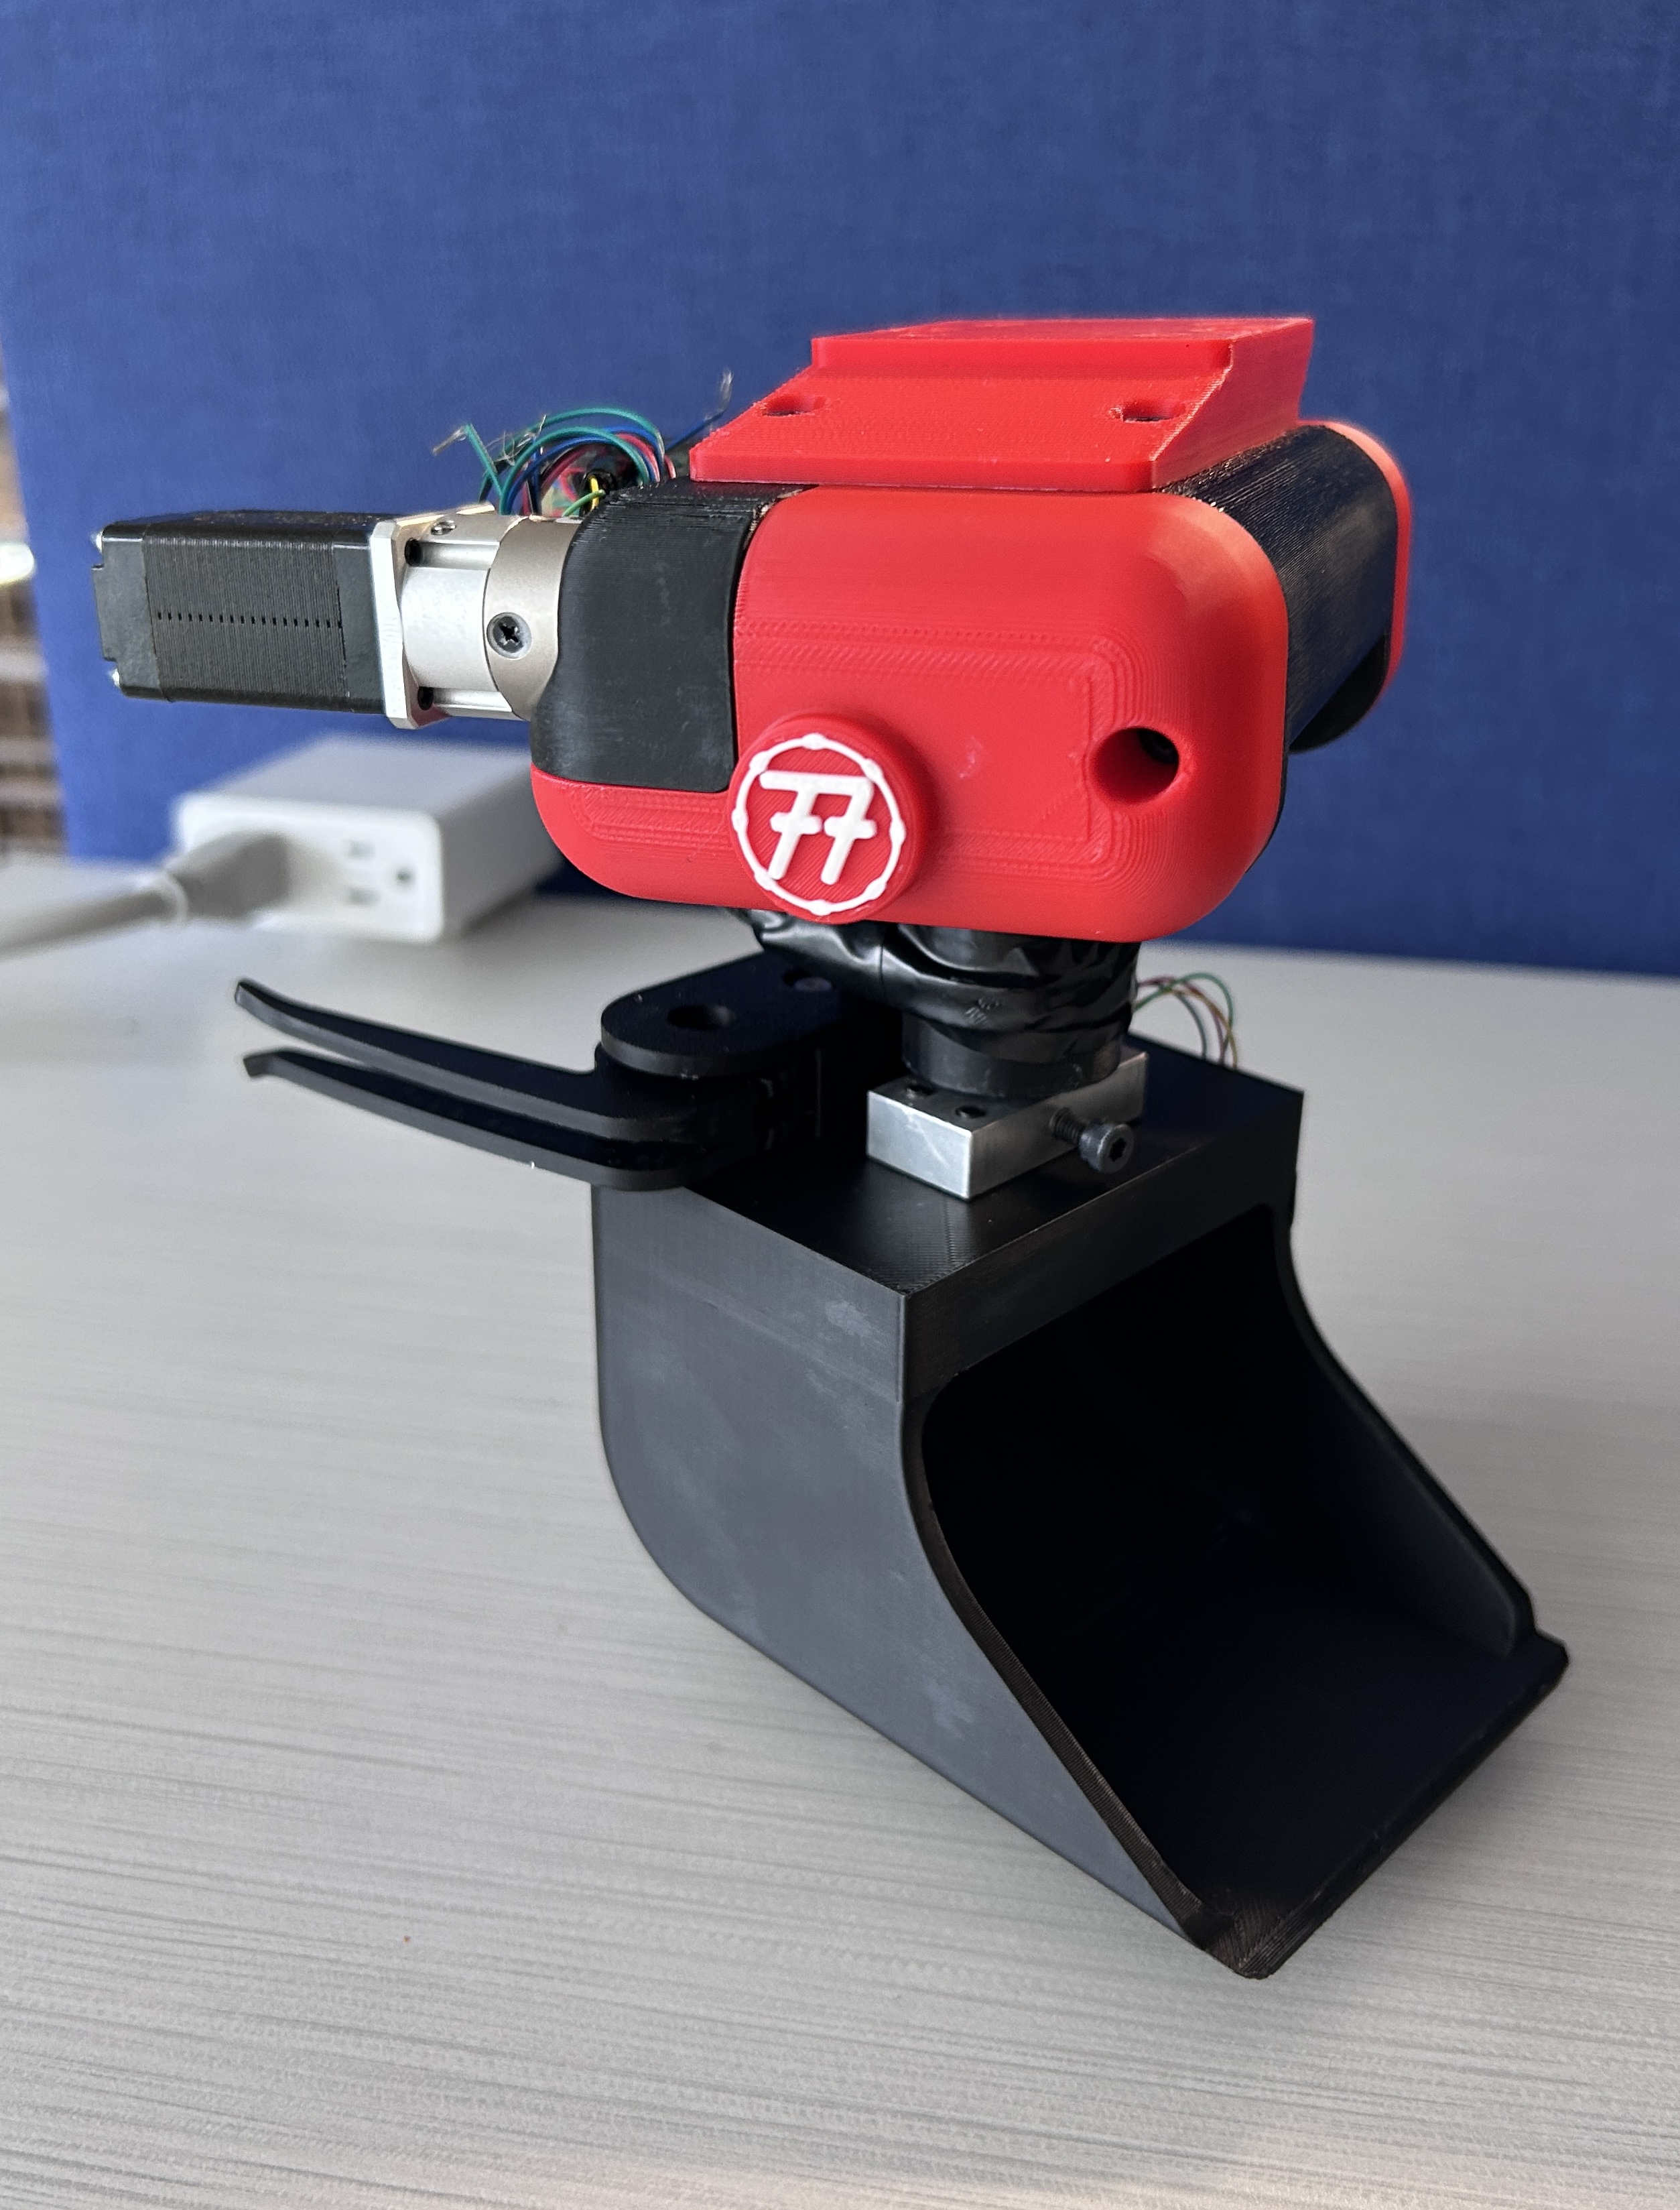
At MIT's The 77 Lab, I helped design and build an electrically actuated tilt rotator for a 1/12-scale excavator. It lets the bucket tilt and rotate, supporting research into teleoperation and operator training.
02 / DESIGN & FABRICATION
From Onshape to a working mechanism
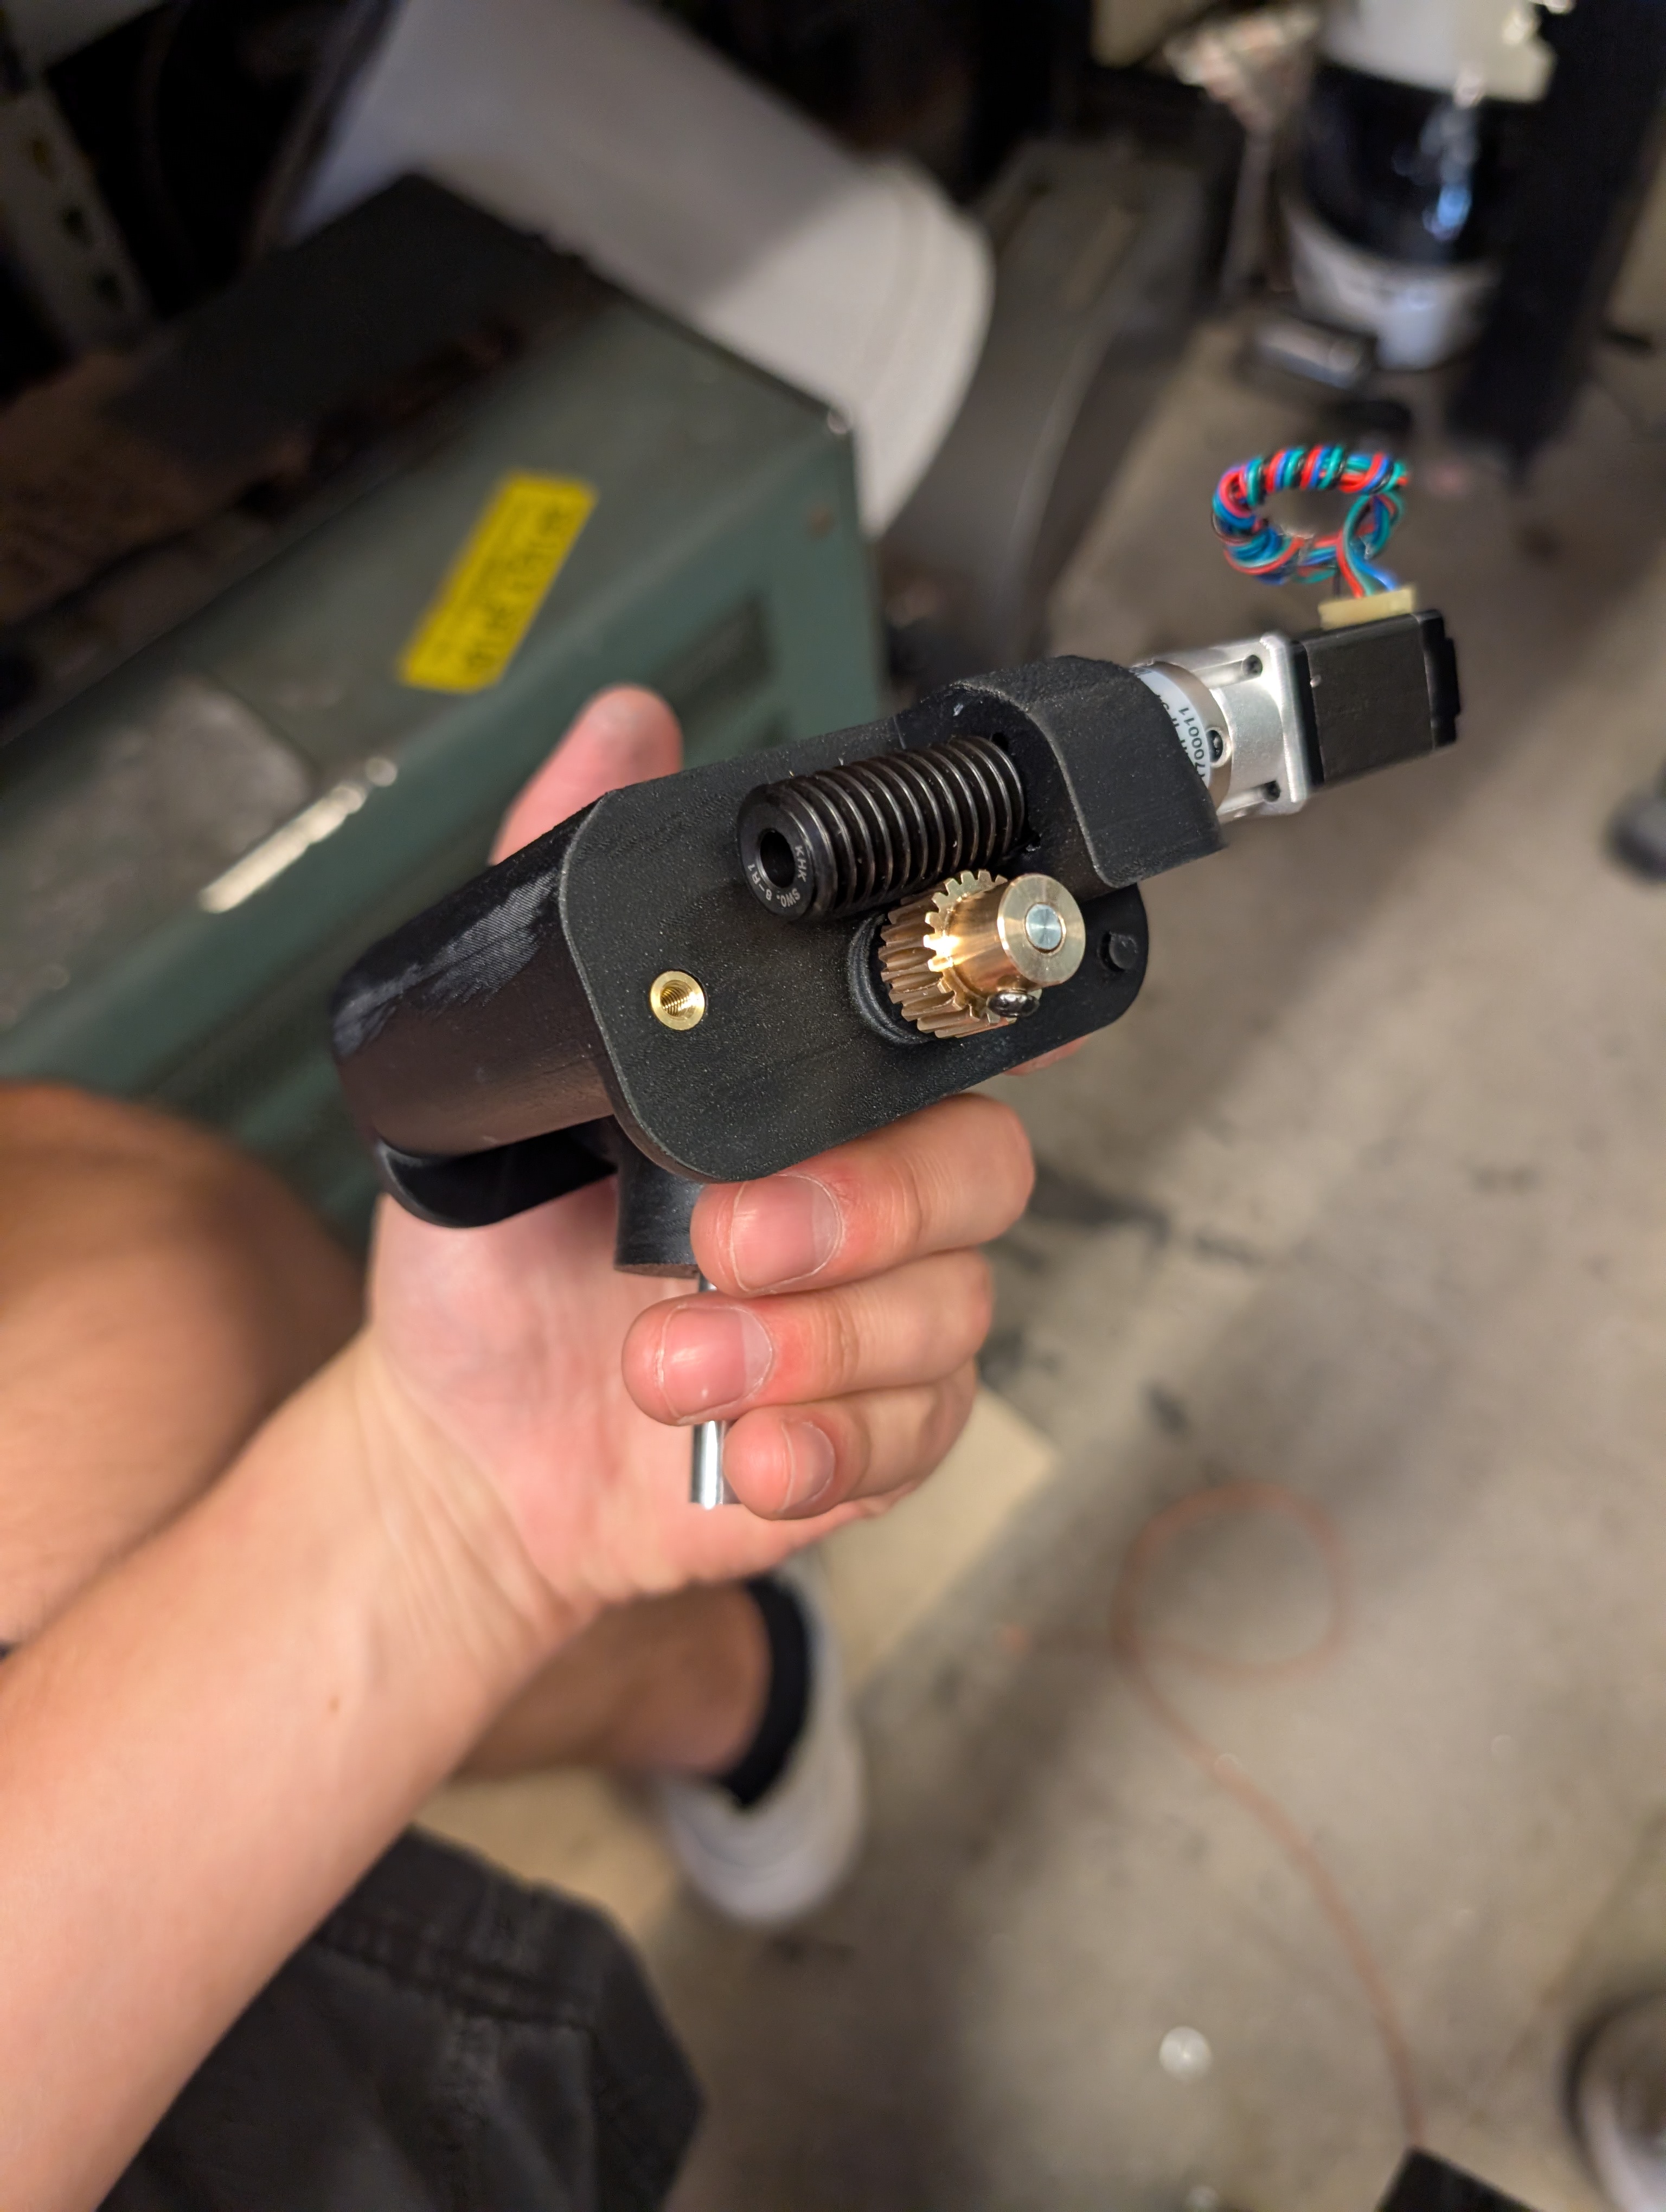
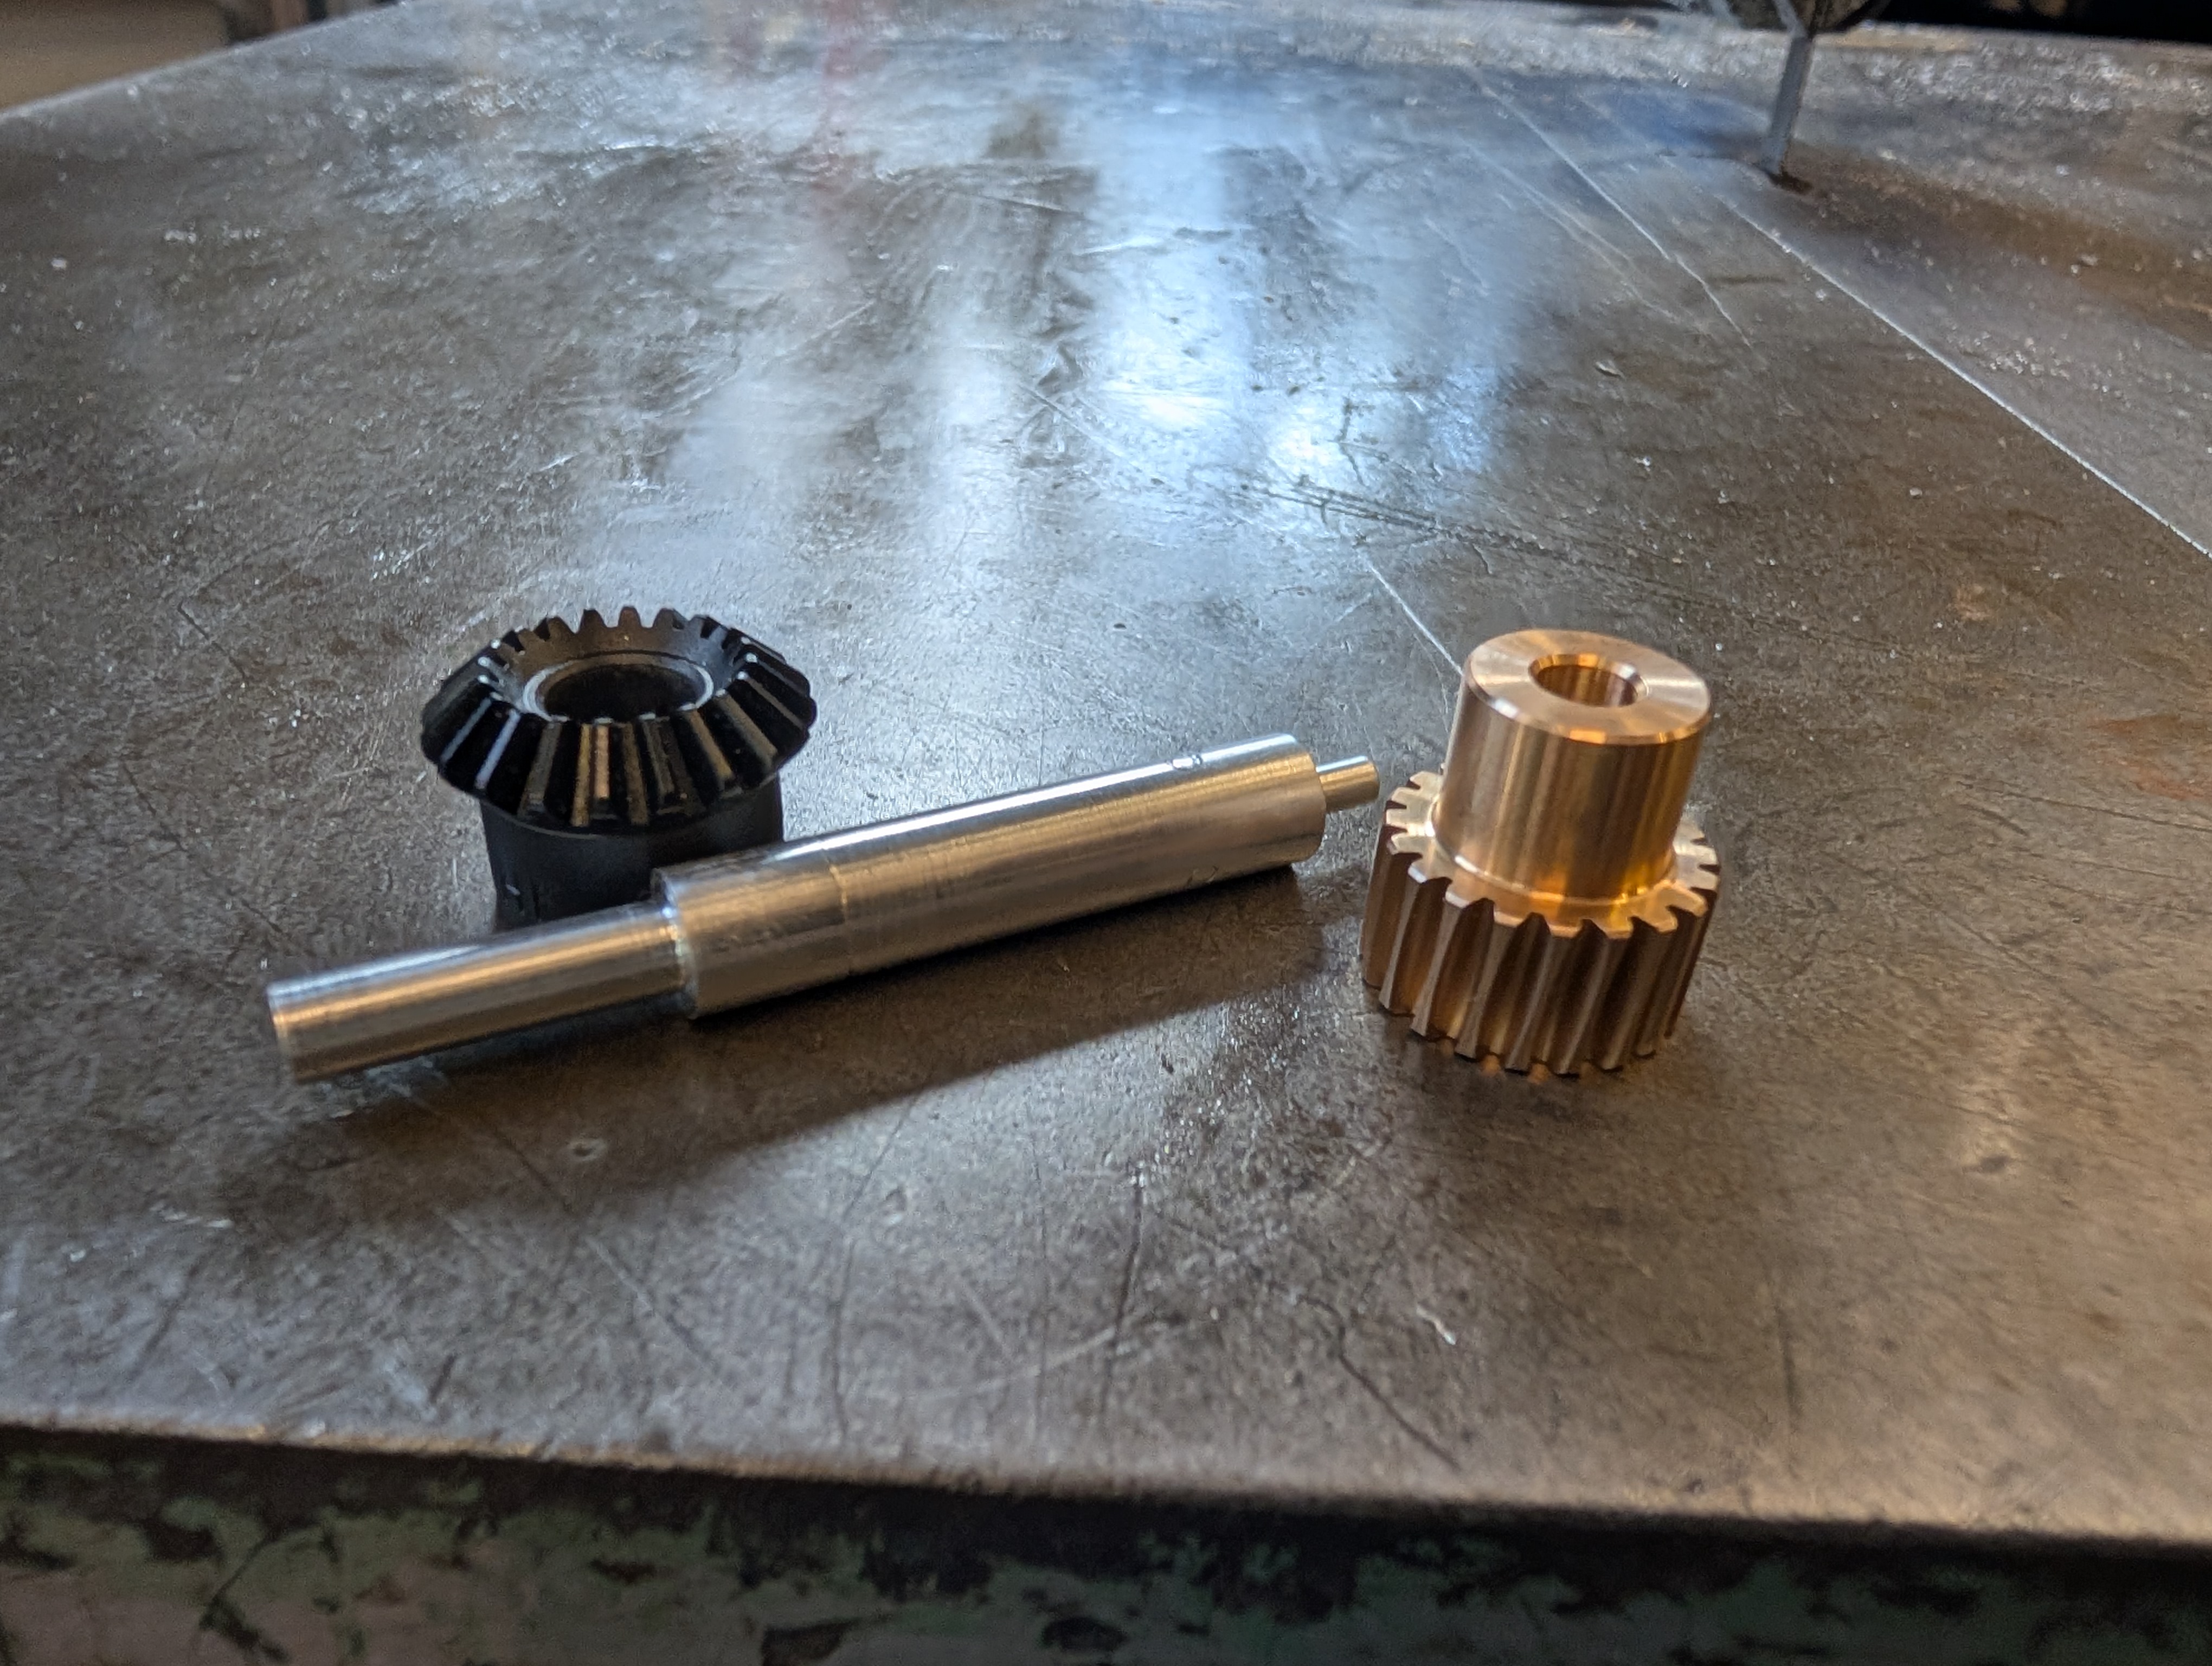
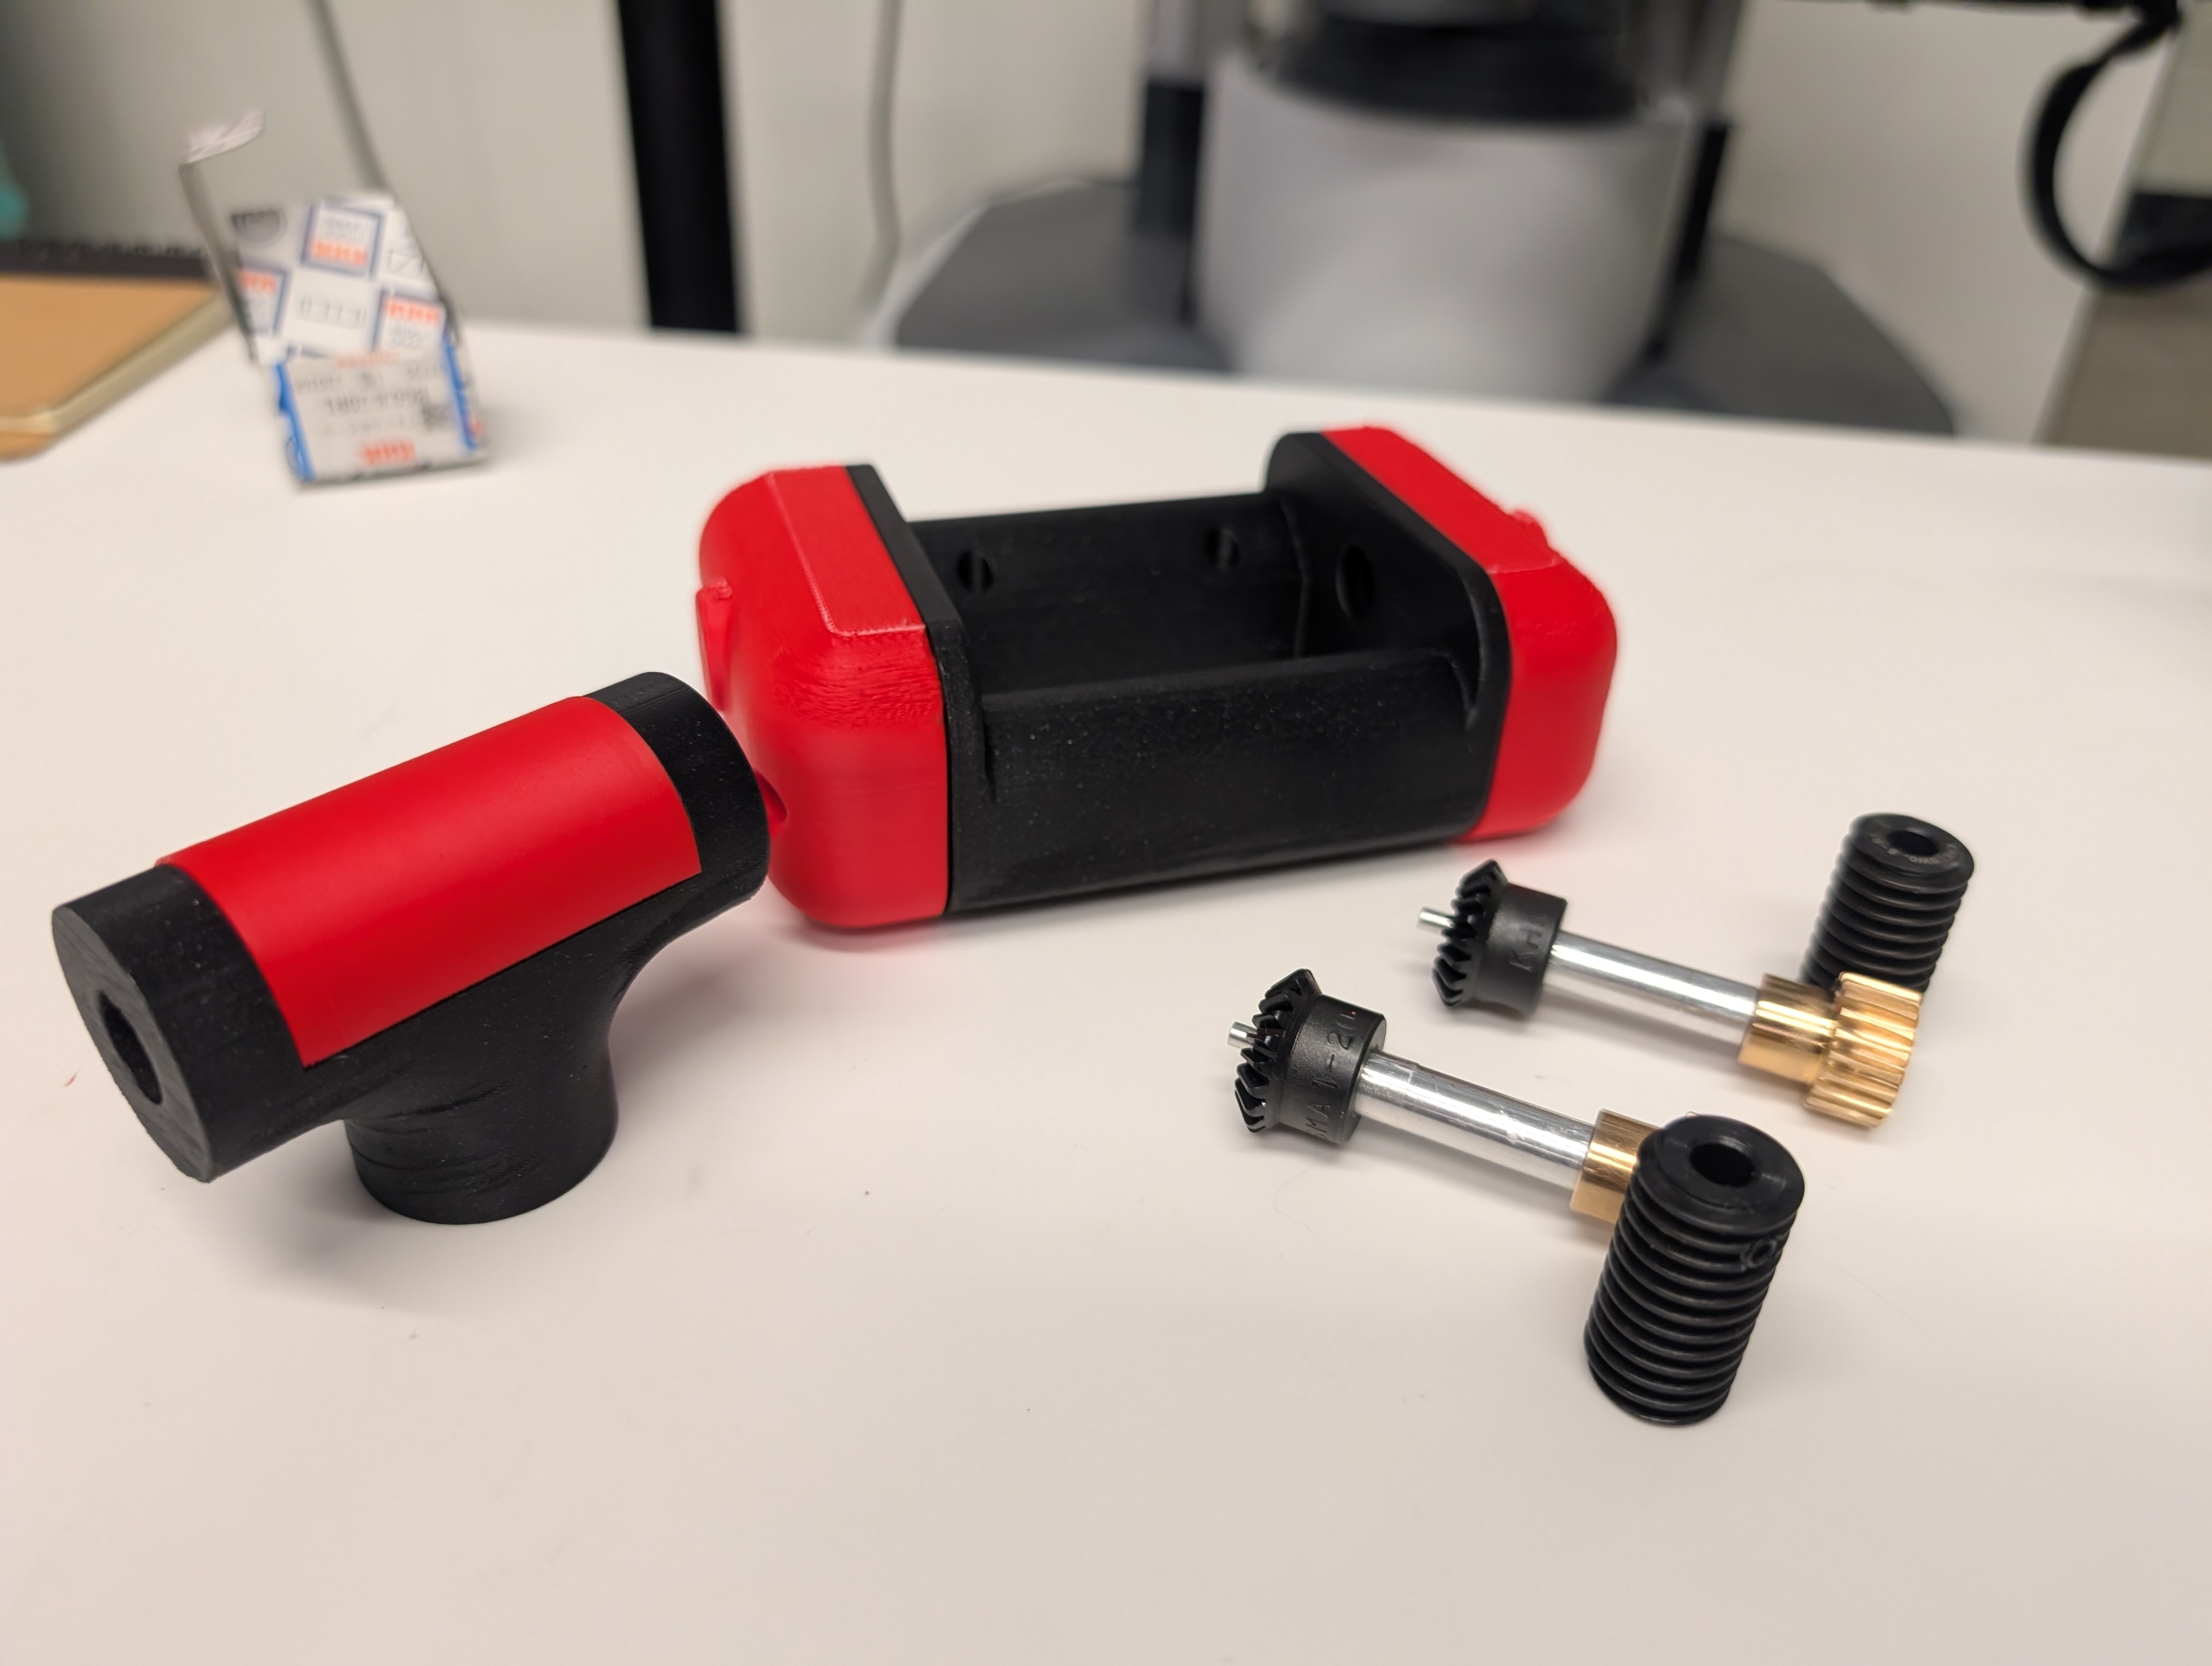
I designed the project in Onshape and 3D printed the main housing components using Bambu Lab printers and slicers. The machined metal parts were made in MITERS at MIT.
I selected the gears and hardware based on the torque they needed to handle, along with efficiency, size, and cost.
03 / IN OPERATION
See the tilt rotator in action
04 / RESEARCH PAPERS
Read the research
Both papers were presented at the 2026 IEEE MIT Undergraduate Research Technology Conference (URTC). Scroll within each preview to browse; use the links below to open or download the full paper.
Electrical & Control Systems
05 / BUILD GALLERY
Development & integration
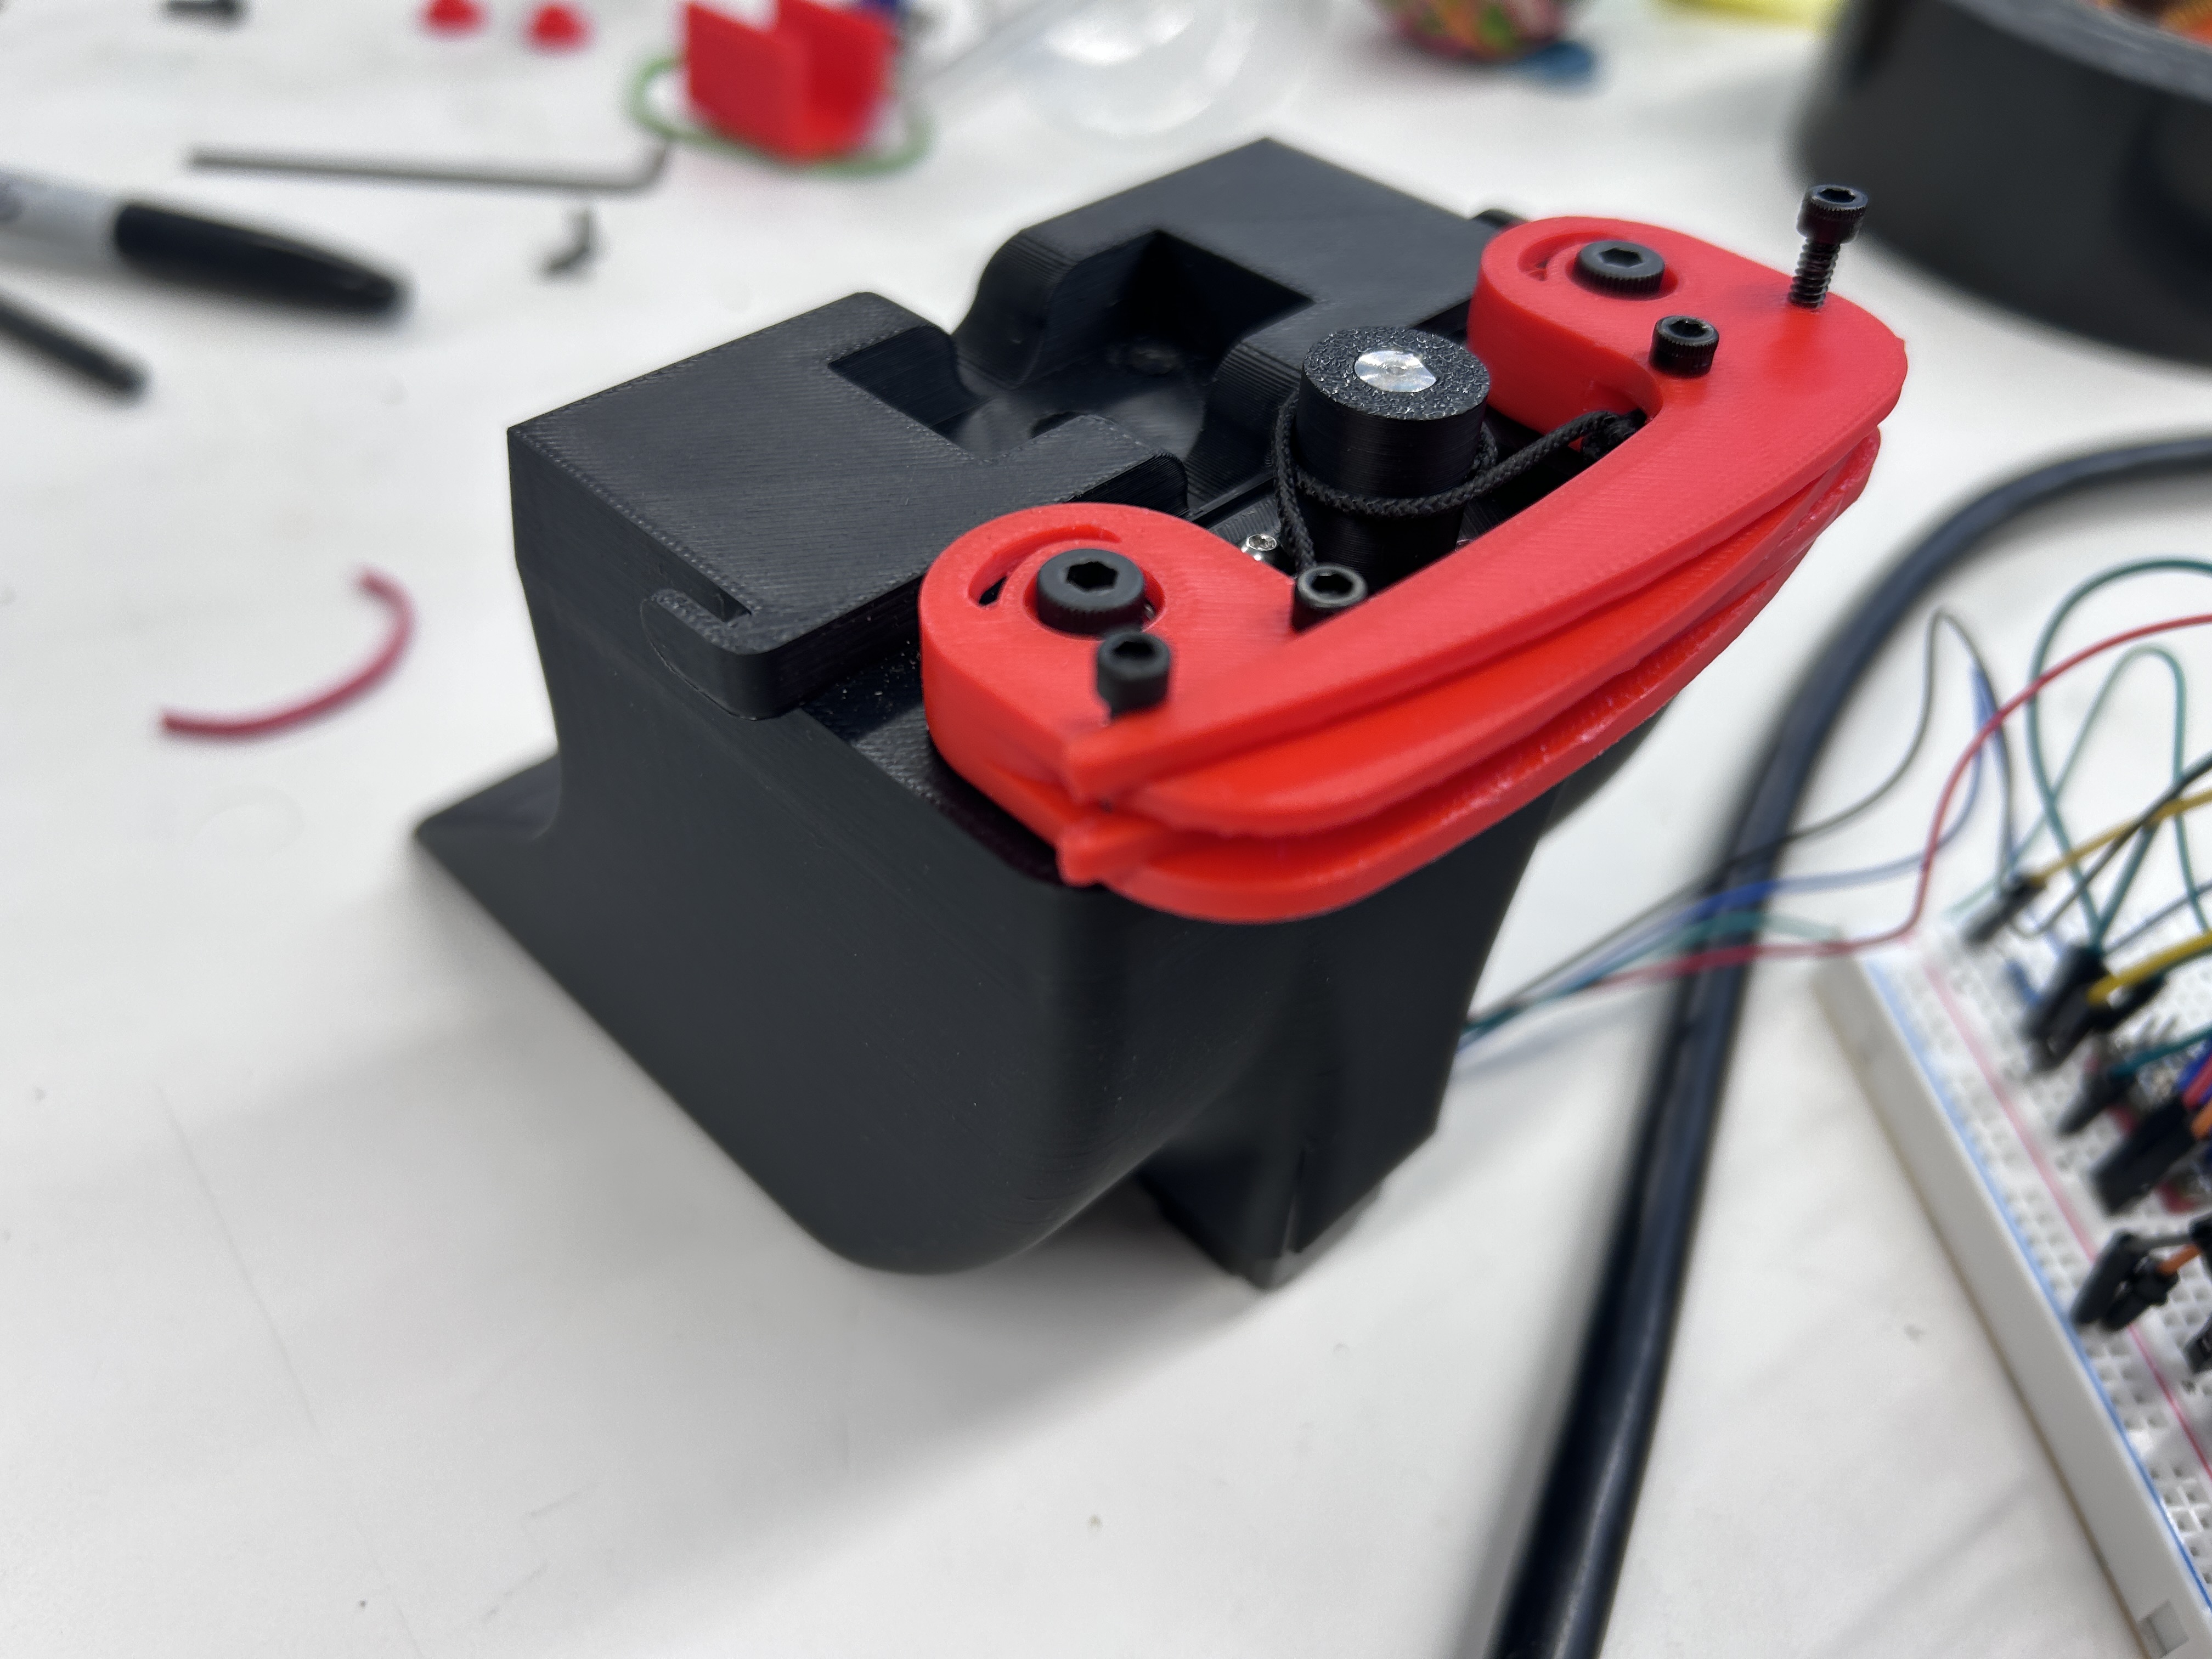
Photos of the tilt rotator, excavator integration, and development process.